Mechanical & hardware engineer

Kumarappan Muthuraman

Pronounced koo-ma-raa-pan moo-to-ramen

I make complex engineering simple. With a great team, anything can be built.

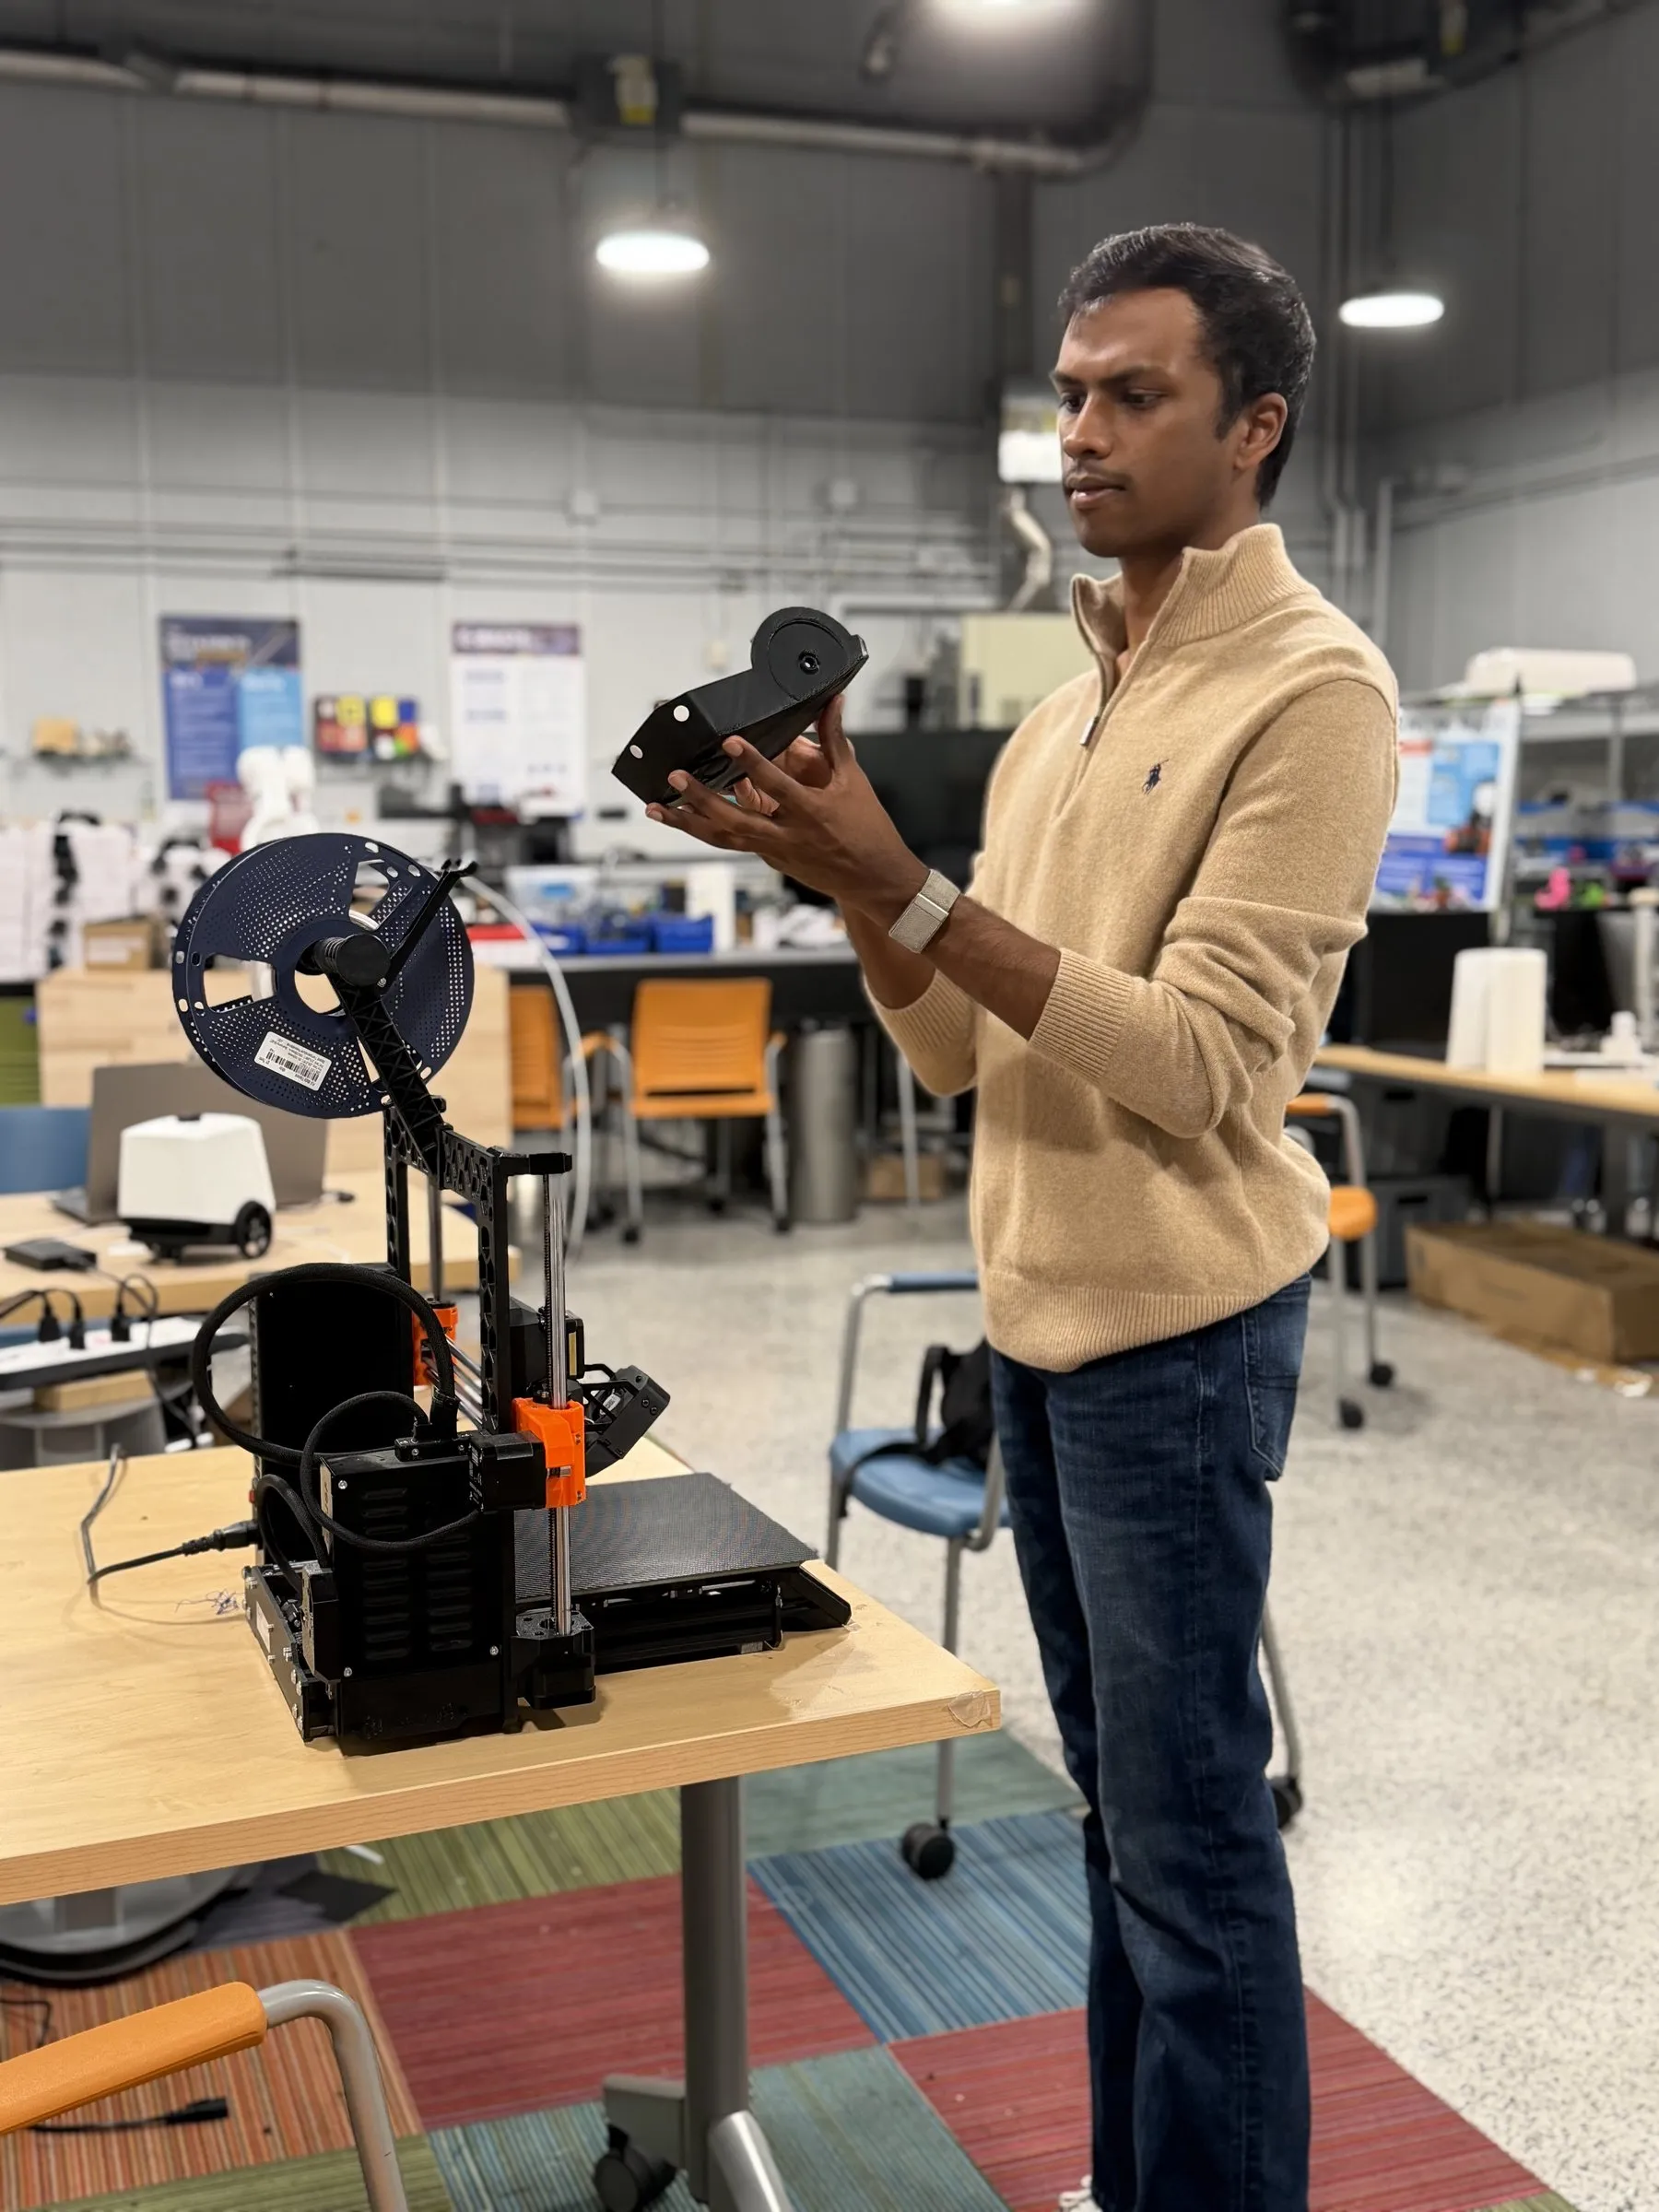
Kumarappan Muthuraman holding a 3D-printed part in a makerspace, next to a 3D printer
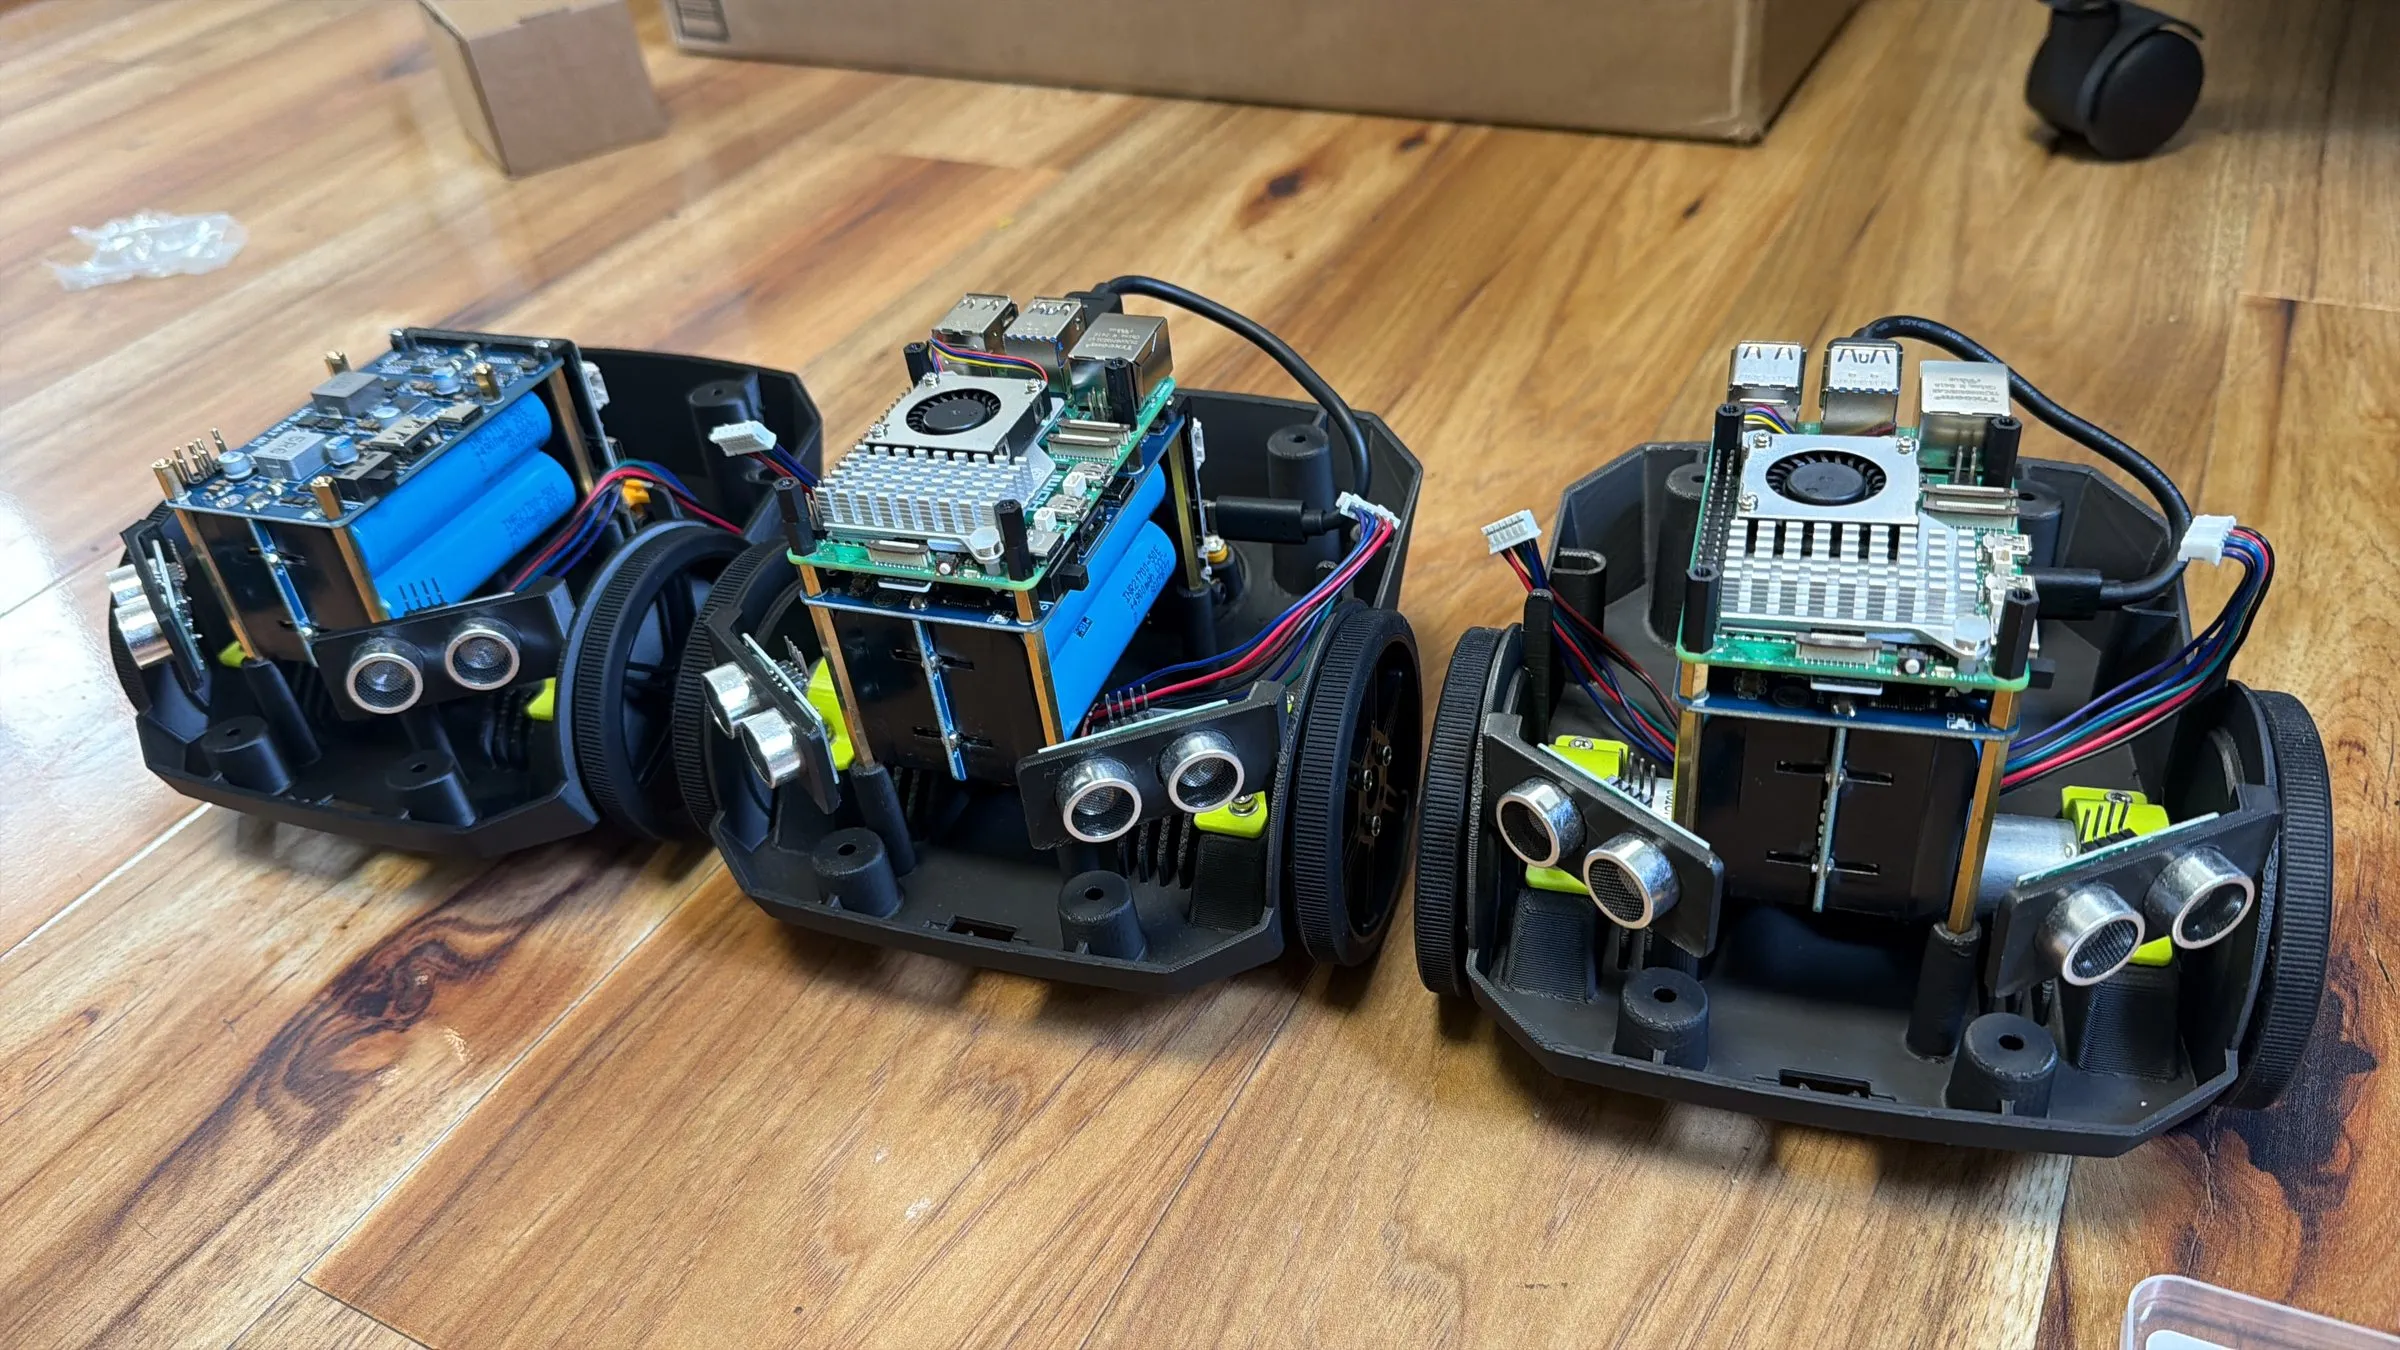
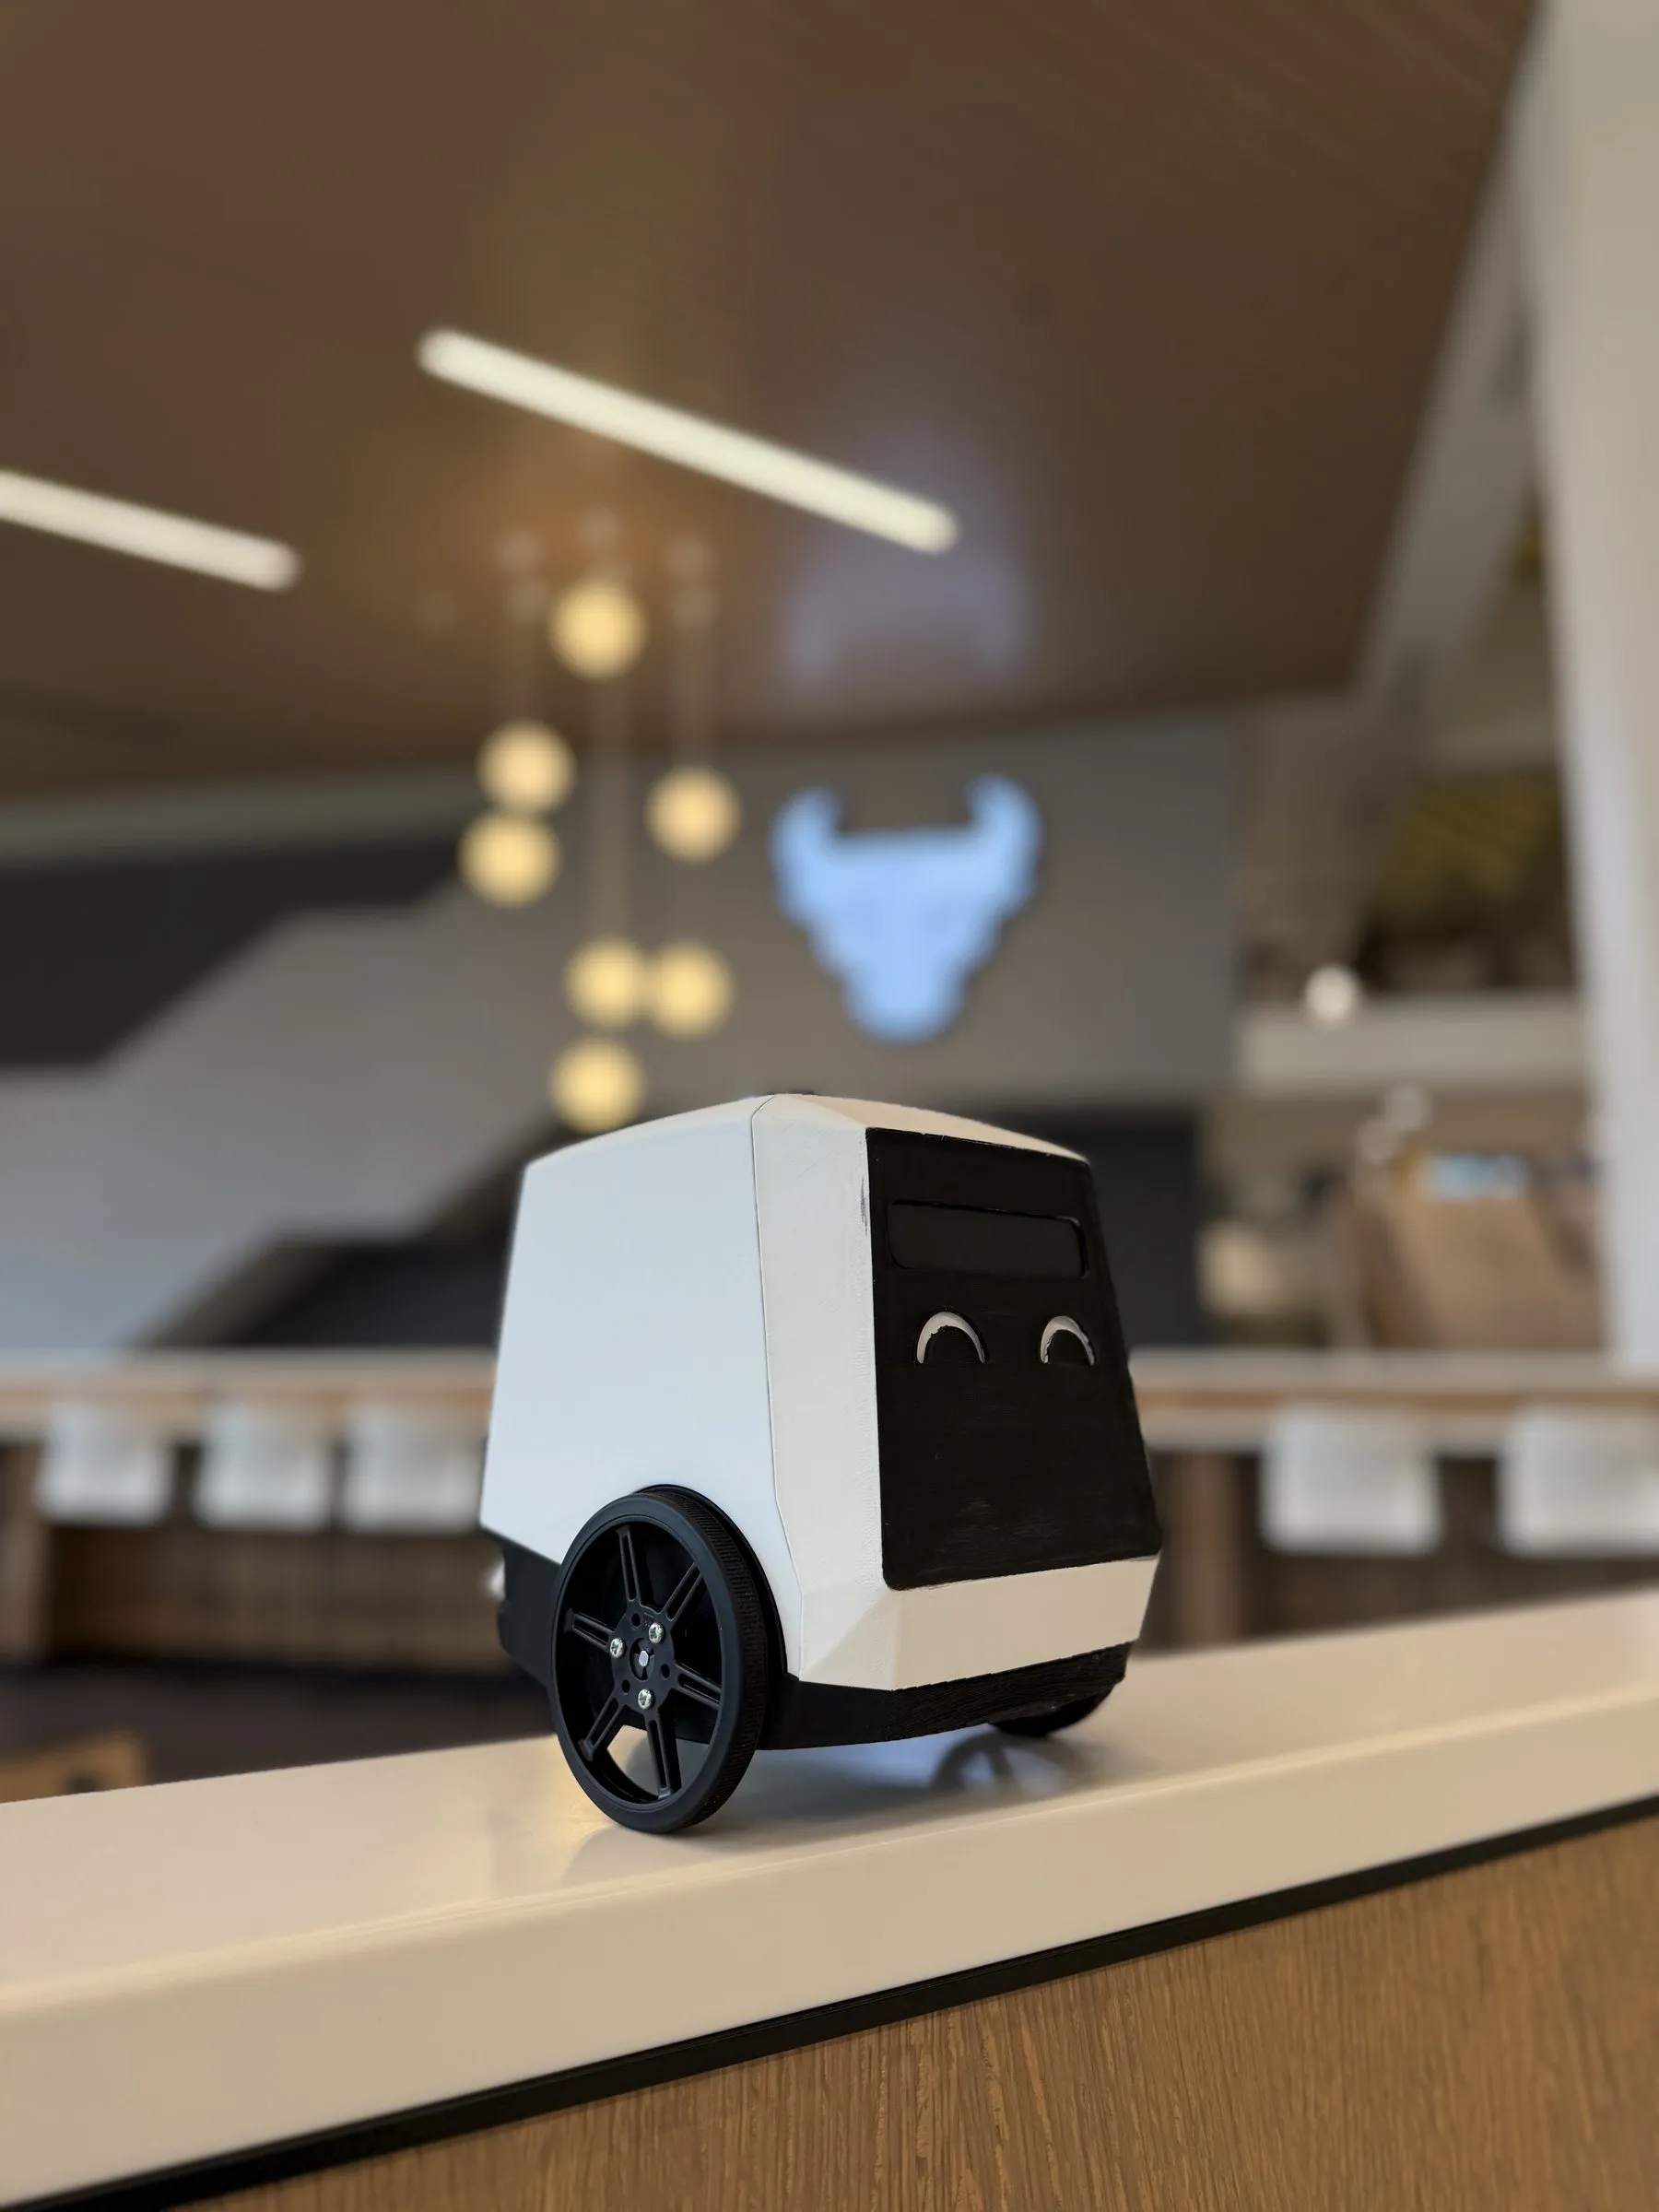
Pebble, the autonomous home robot I am building at Pebble Robotics. Film on YouTube, with sound.

Selected work · 4

From first prototype to production

Each case study covers what I owned, the decisions that mattered and the measured results.

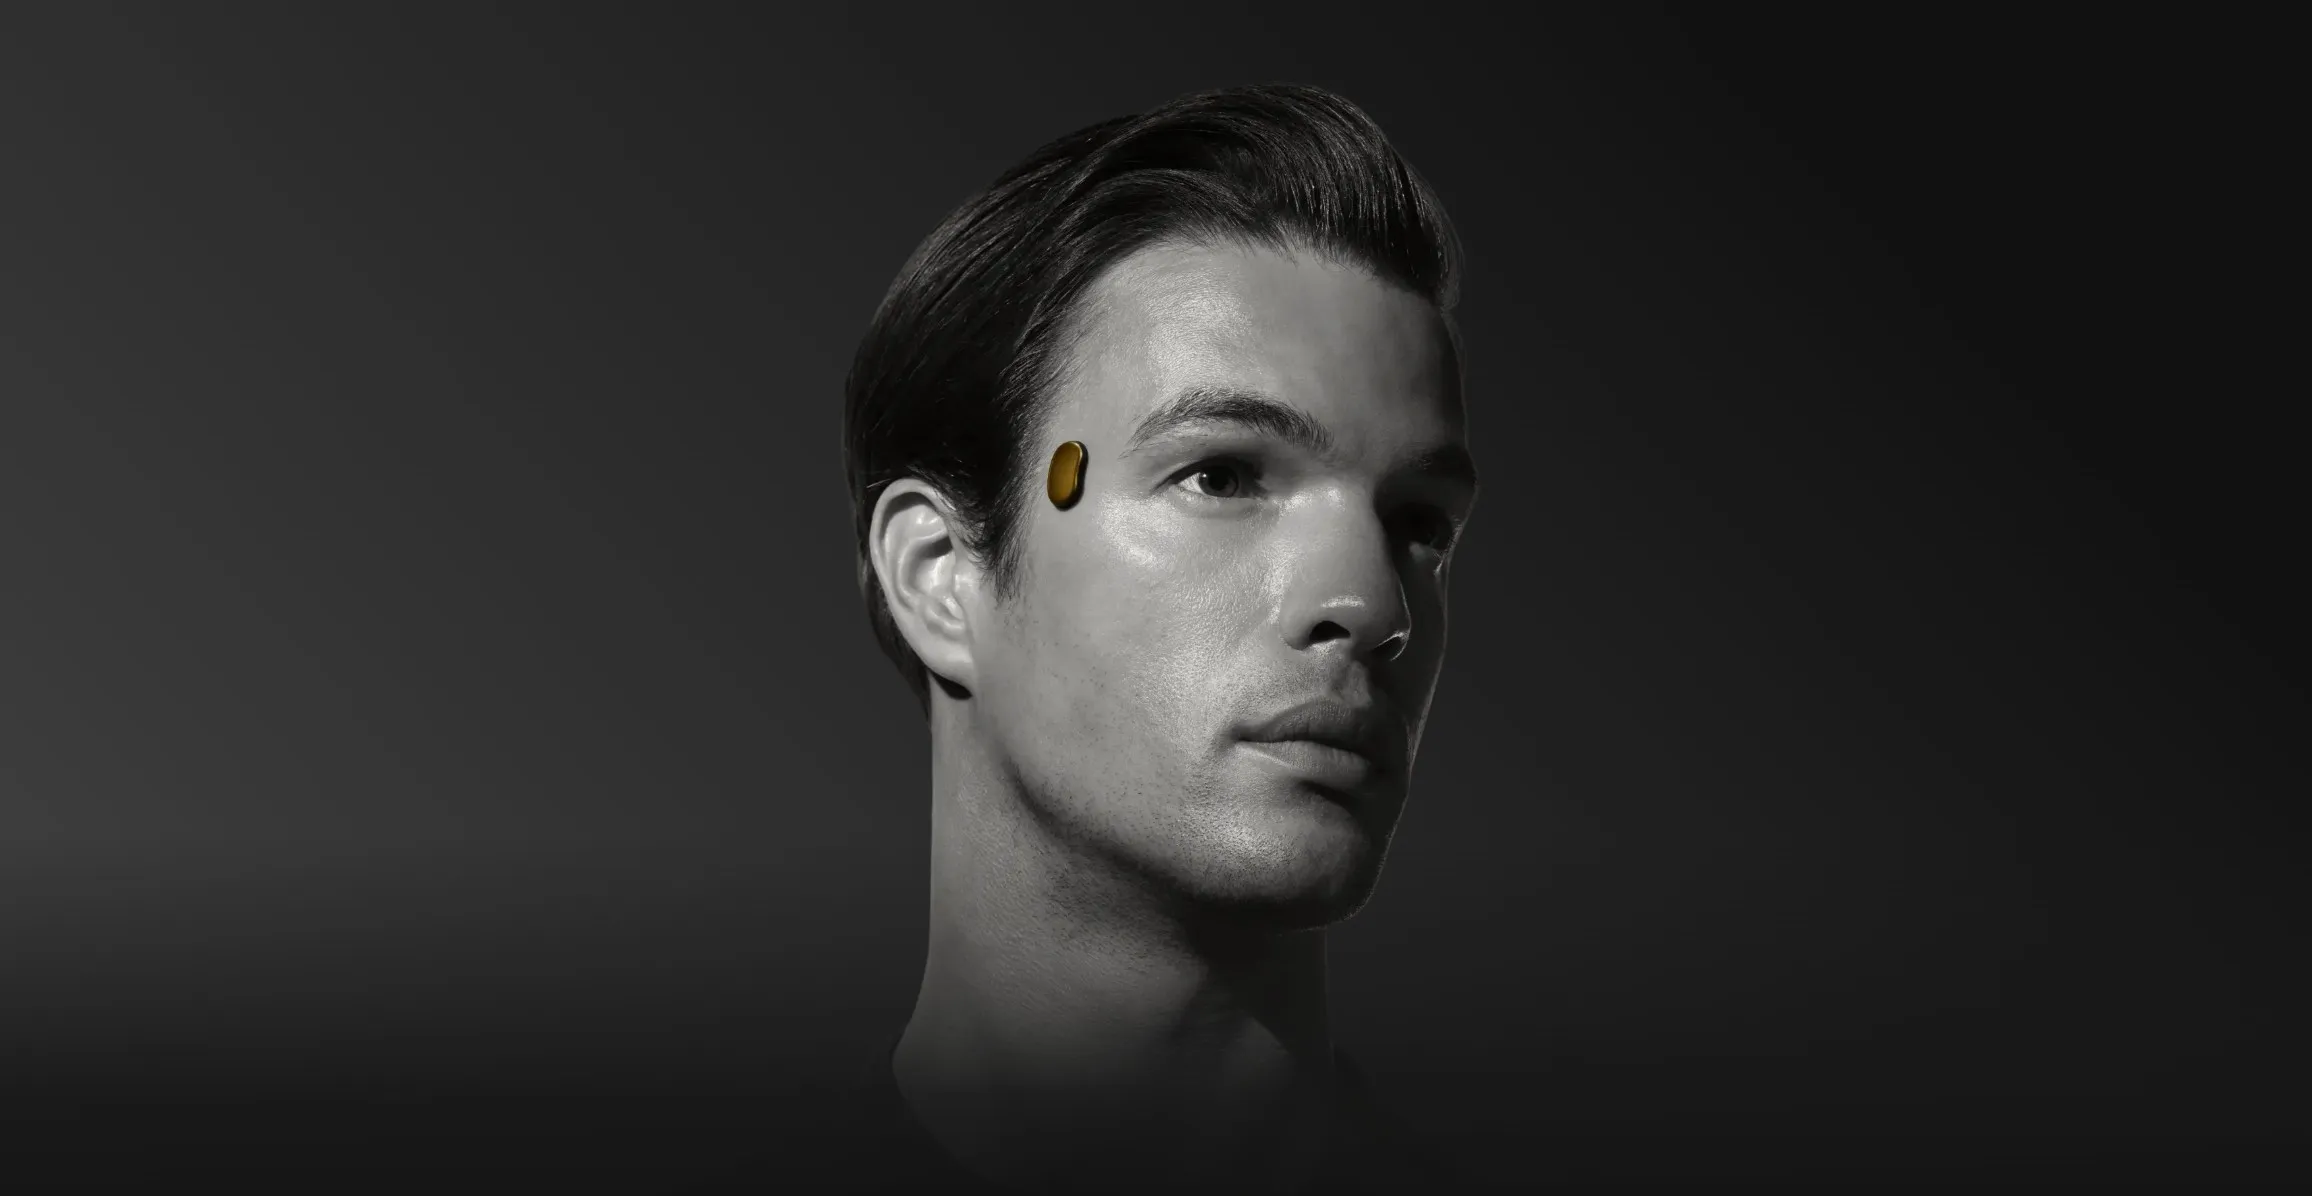
A person wearing TEMPLE's small gold wearable on the side of the head, at the temple

TEMPLE · Sep 2024 – Jun 2025

Cerebral blood-flow wearable

A sub-4 mm neuro wearable, taken from R&D to production

A wearable that monitors blood flow to the brain continuously and non-invasively, in a package under 4 mm thick. I owned the hardware from system design to production and built the first 200 units in-house in two months.

< 4 mm
Device thickness
200
Units built and shipped in-house
2 months
To build and ship those first 200
Read the case study →

TEMPLE raised $54 million in its first funding round in February 2026, at a $190 million valuation.

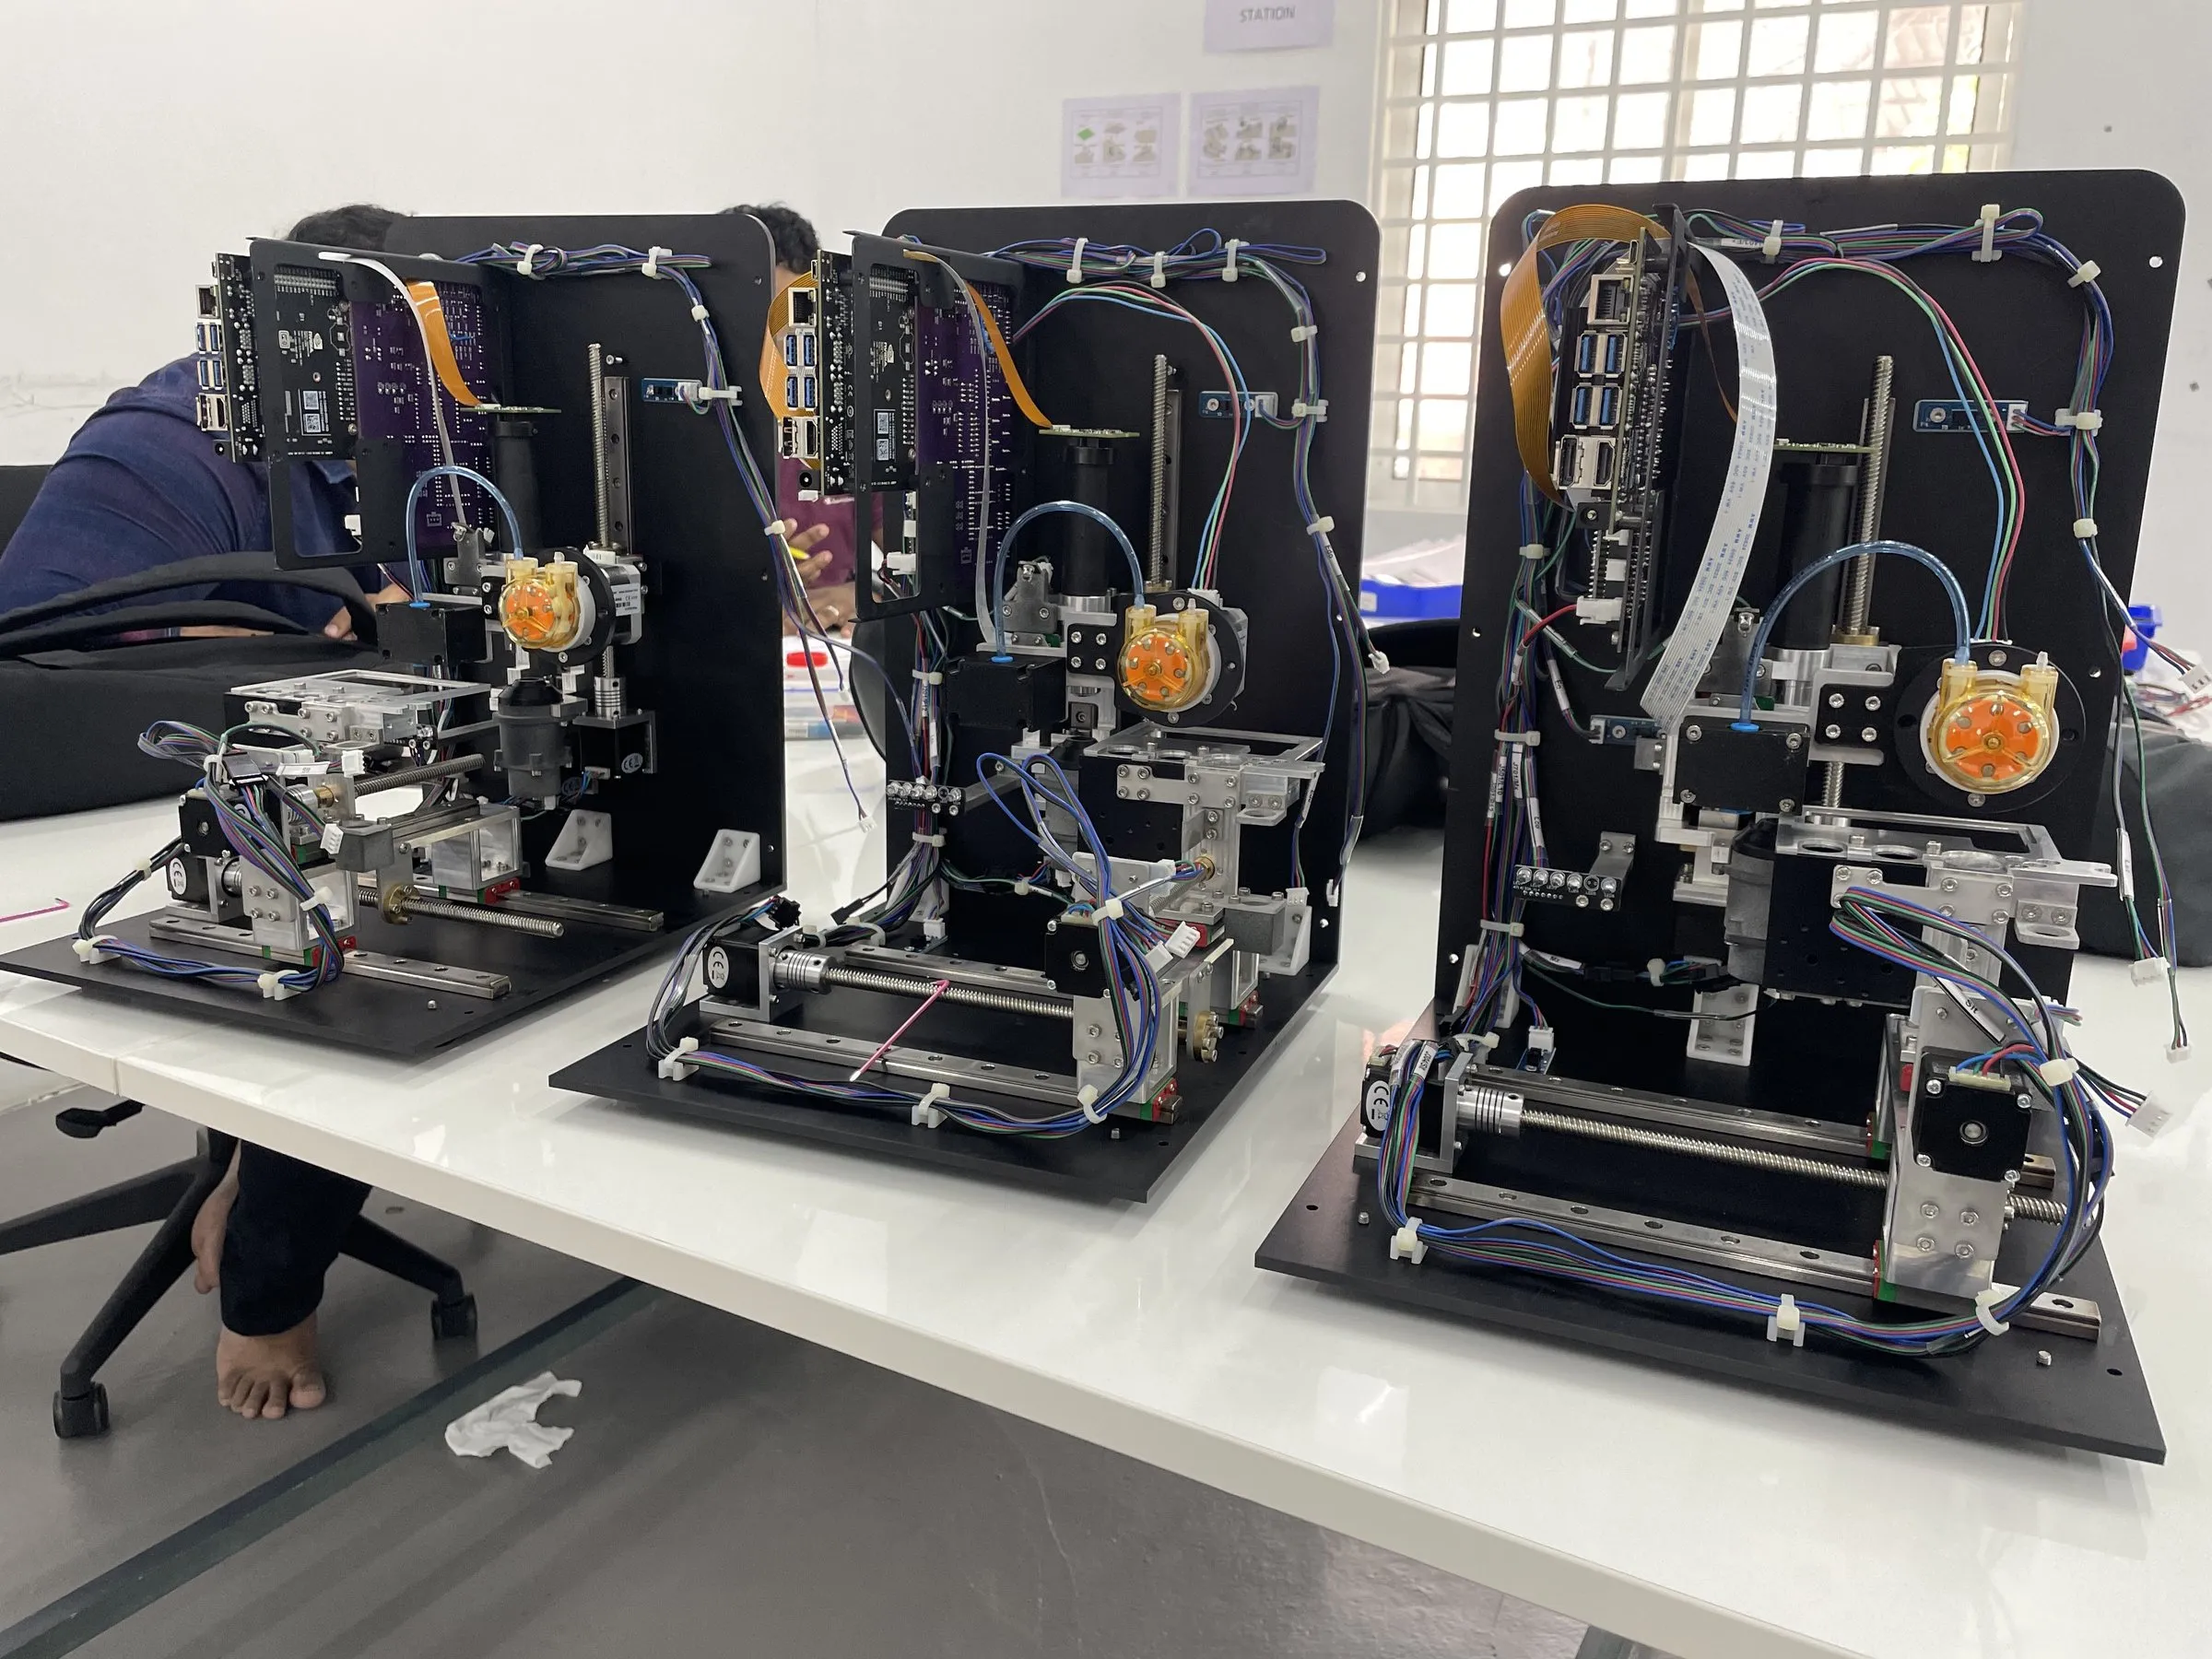
Three open CBC analyzers on a bench, showing the pumps, gantry and optics inside

PIIKO · Nov 2021 – Aug 2024

CBC blood analyzer

A complete blood count analyzer, from design to 50+ units in the field

A compact complete blood count analyzer that combines optical imaging, micro-volume fluidics and a precision scanning gantry in a 1 ft × 1 ft unit of about 5 kg. I led its design through production. More than 50 units shipped to hospitals and labs, at 10× lower cost per test.

50+
Analyzers shipped to hospitals and labs
10×
Lower cost per test, through DFX
20+ a day
Assembly rate with a five-person team
Read the case study →
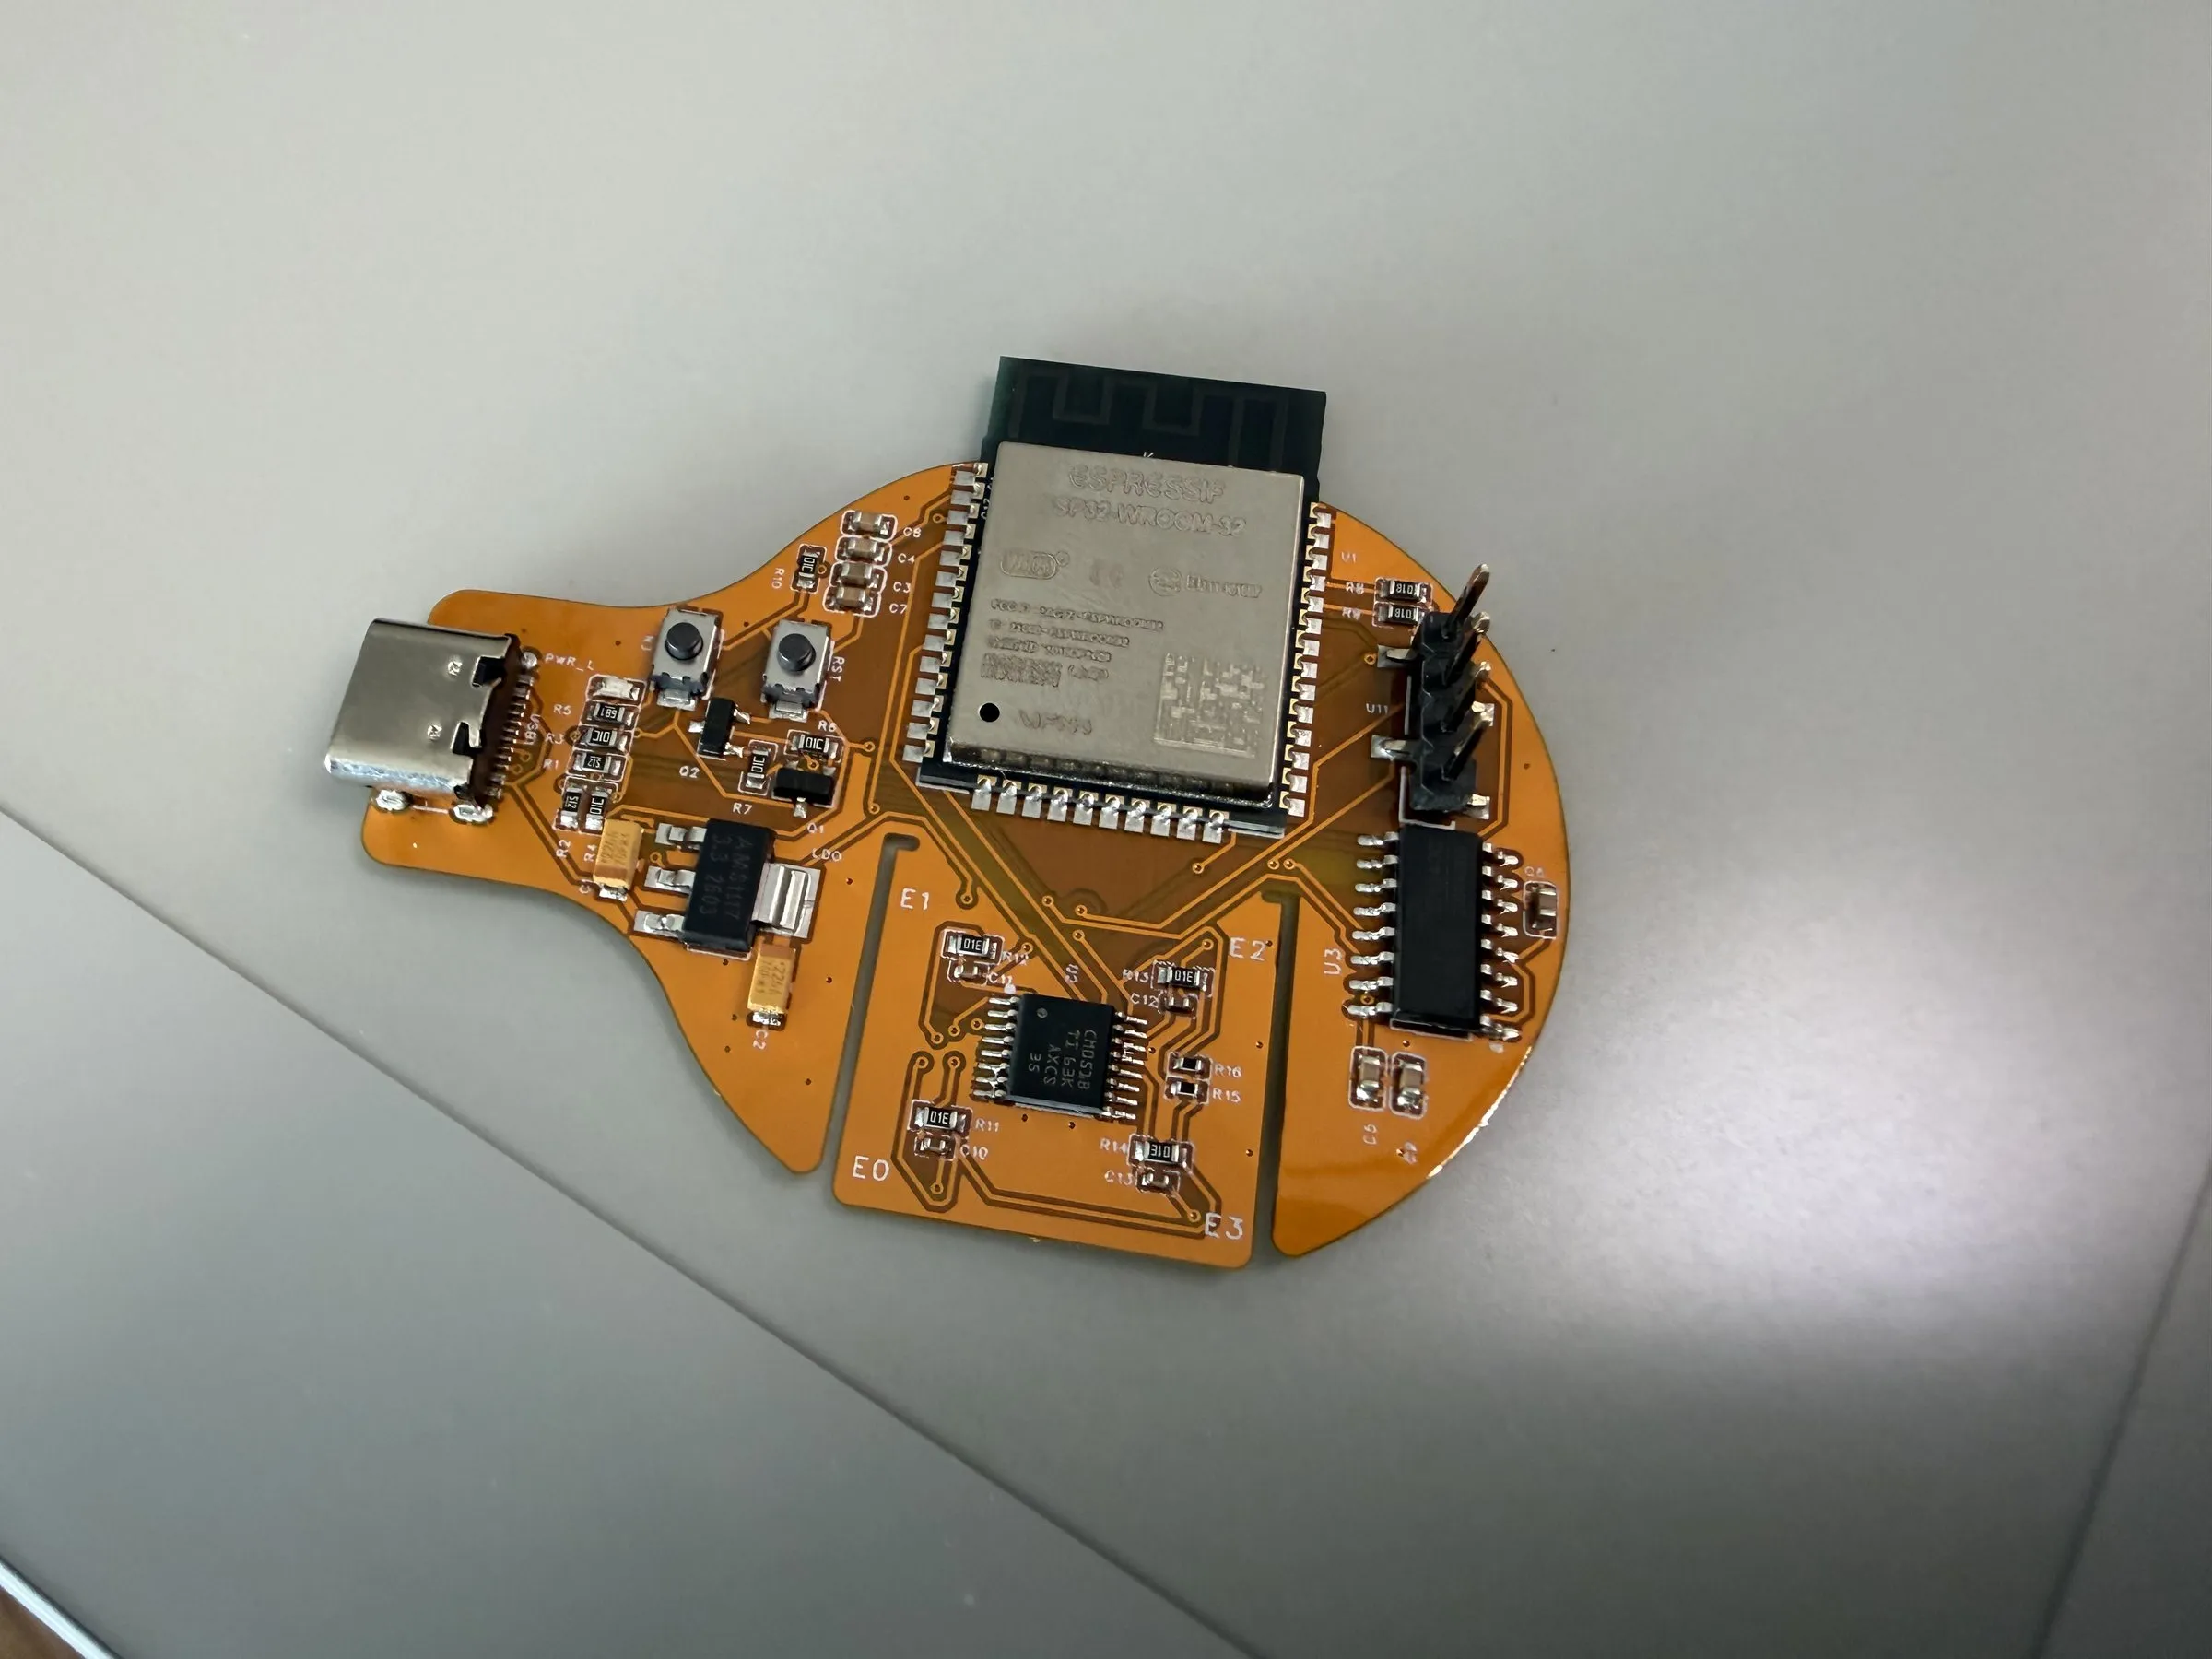
Orange flex PCB prototype of the EMG wearable, component side, with an ESP32 module and USB-C connector

University at Buffalo · Sep 2025 – present

High-density EMG wearable

High-density muscle sensing through one shared amplifier chain

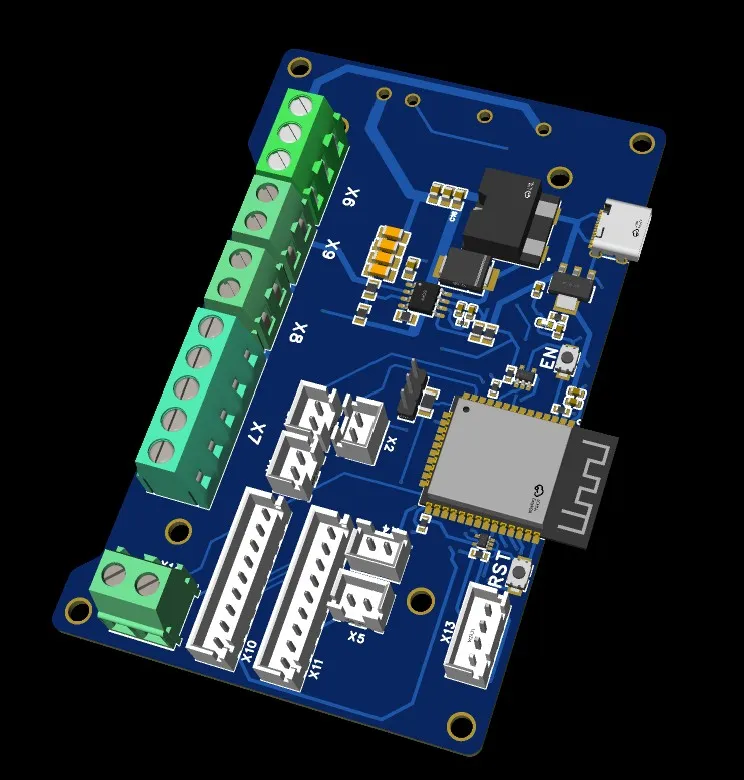
A wearable for high-density surface EMG that routes every channel through one multiplexed amplifier chain instead of one chain per channel. The first prototype has four electrodes, and I am expanding it to 8 channels. I own the analog front end, the flex PCB and the electrode-array enclosure.

4
Electrodes on the first prototype
8
Channels in the version I'm building now
1
Shared amplifier chain for every channel
Read the case study →

Founder · 2

Two hardware startups, started from zero

I build companies the way I build machines: prototype fast, then make it work in production.

Kumar and a Pebble Robotics teammate giving a thumbs-up in front of a large window

2026 – present · Buffalo, NY

Current

Pebble Robotics

Co-founder

An autonomous home robot that maps a home and senses what happens in it, without cameras or wearables.

  • Built the first complete robot alone in four months
  • Formed a five-person team for mapping, voice and cloud
  • Building five units for a pilot study

Advisors

  • Dr. Machiko TomitaOccupational therapy and rehabilitation science
  • Dr. Nikhil SatchidanandResearch advisor
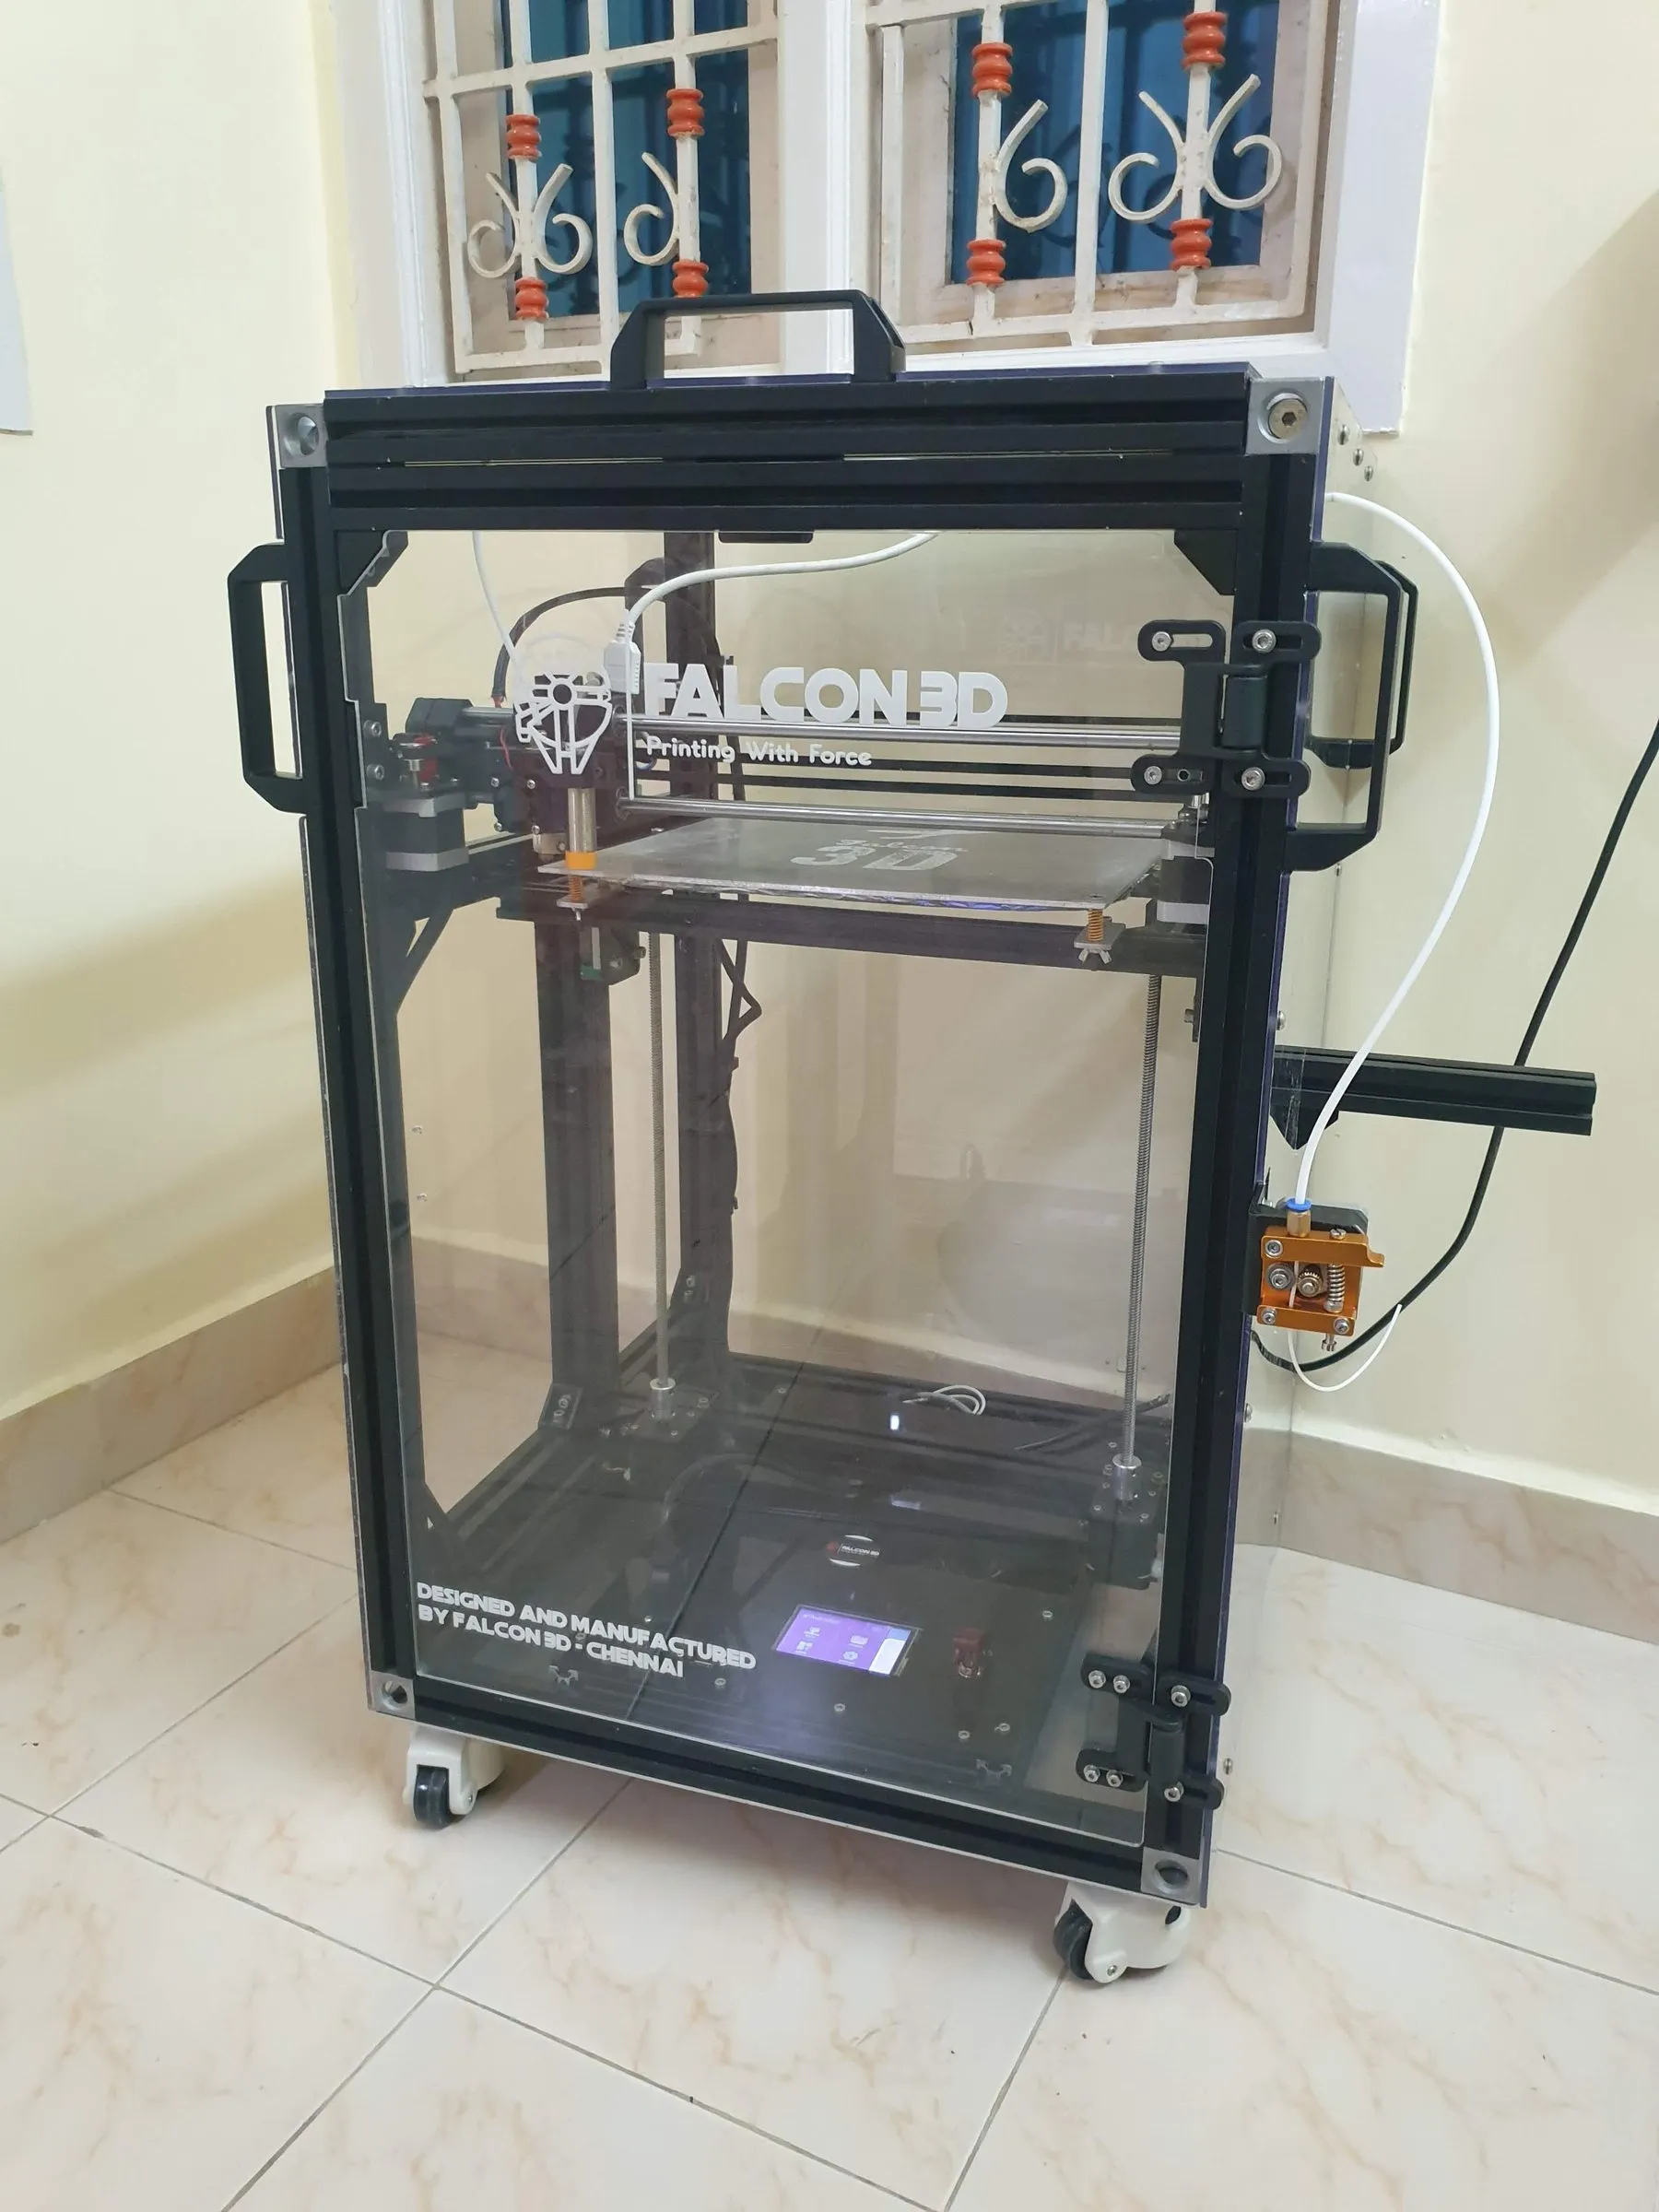
An enclosed Falcon 3D printer with the Falcon 3D logo on its front panel

2017 – 2020 · India

Falcon 3D

Founder & CEO

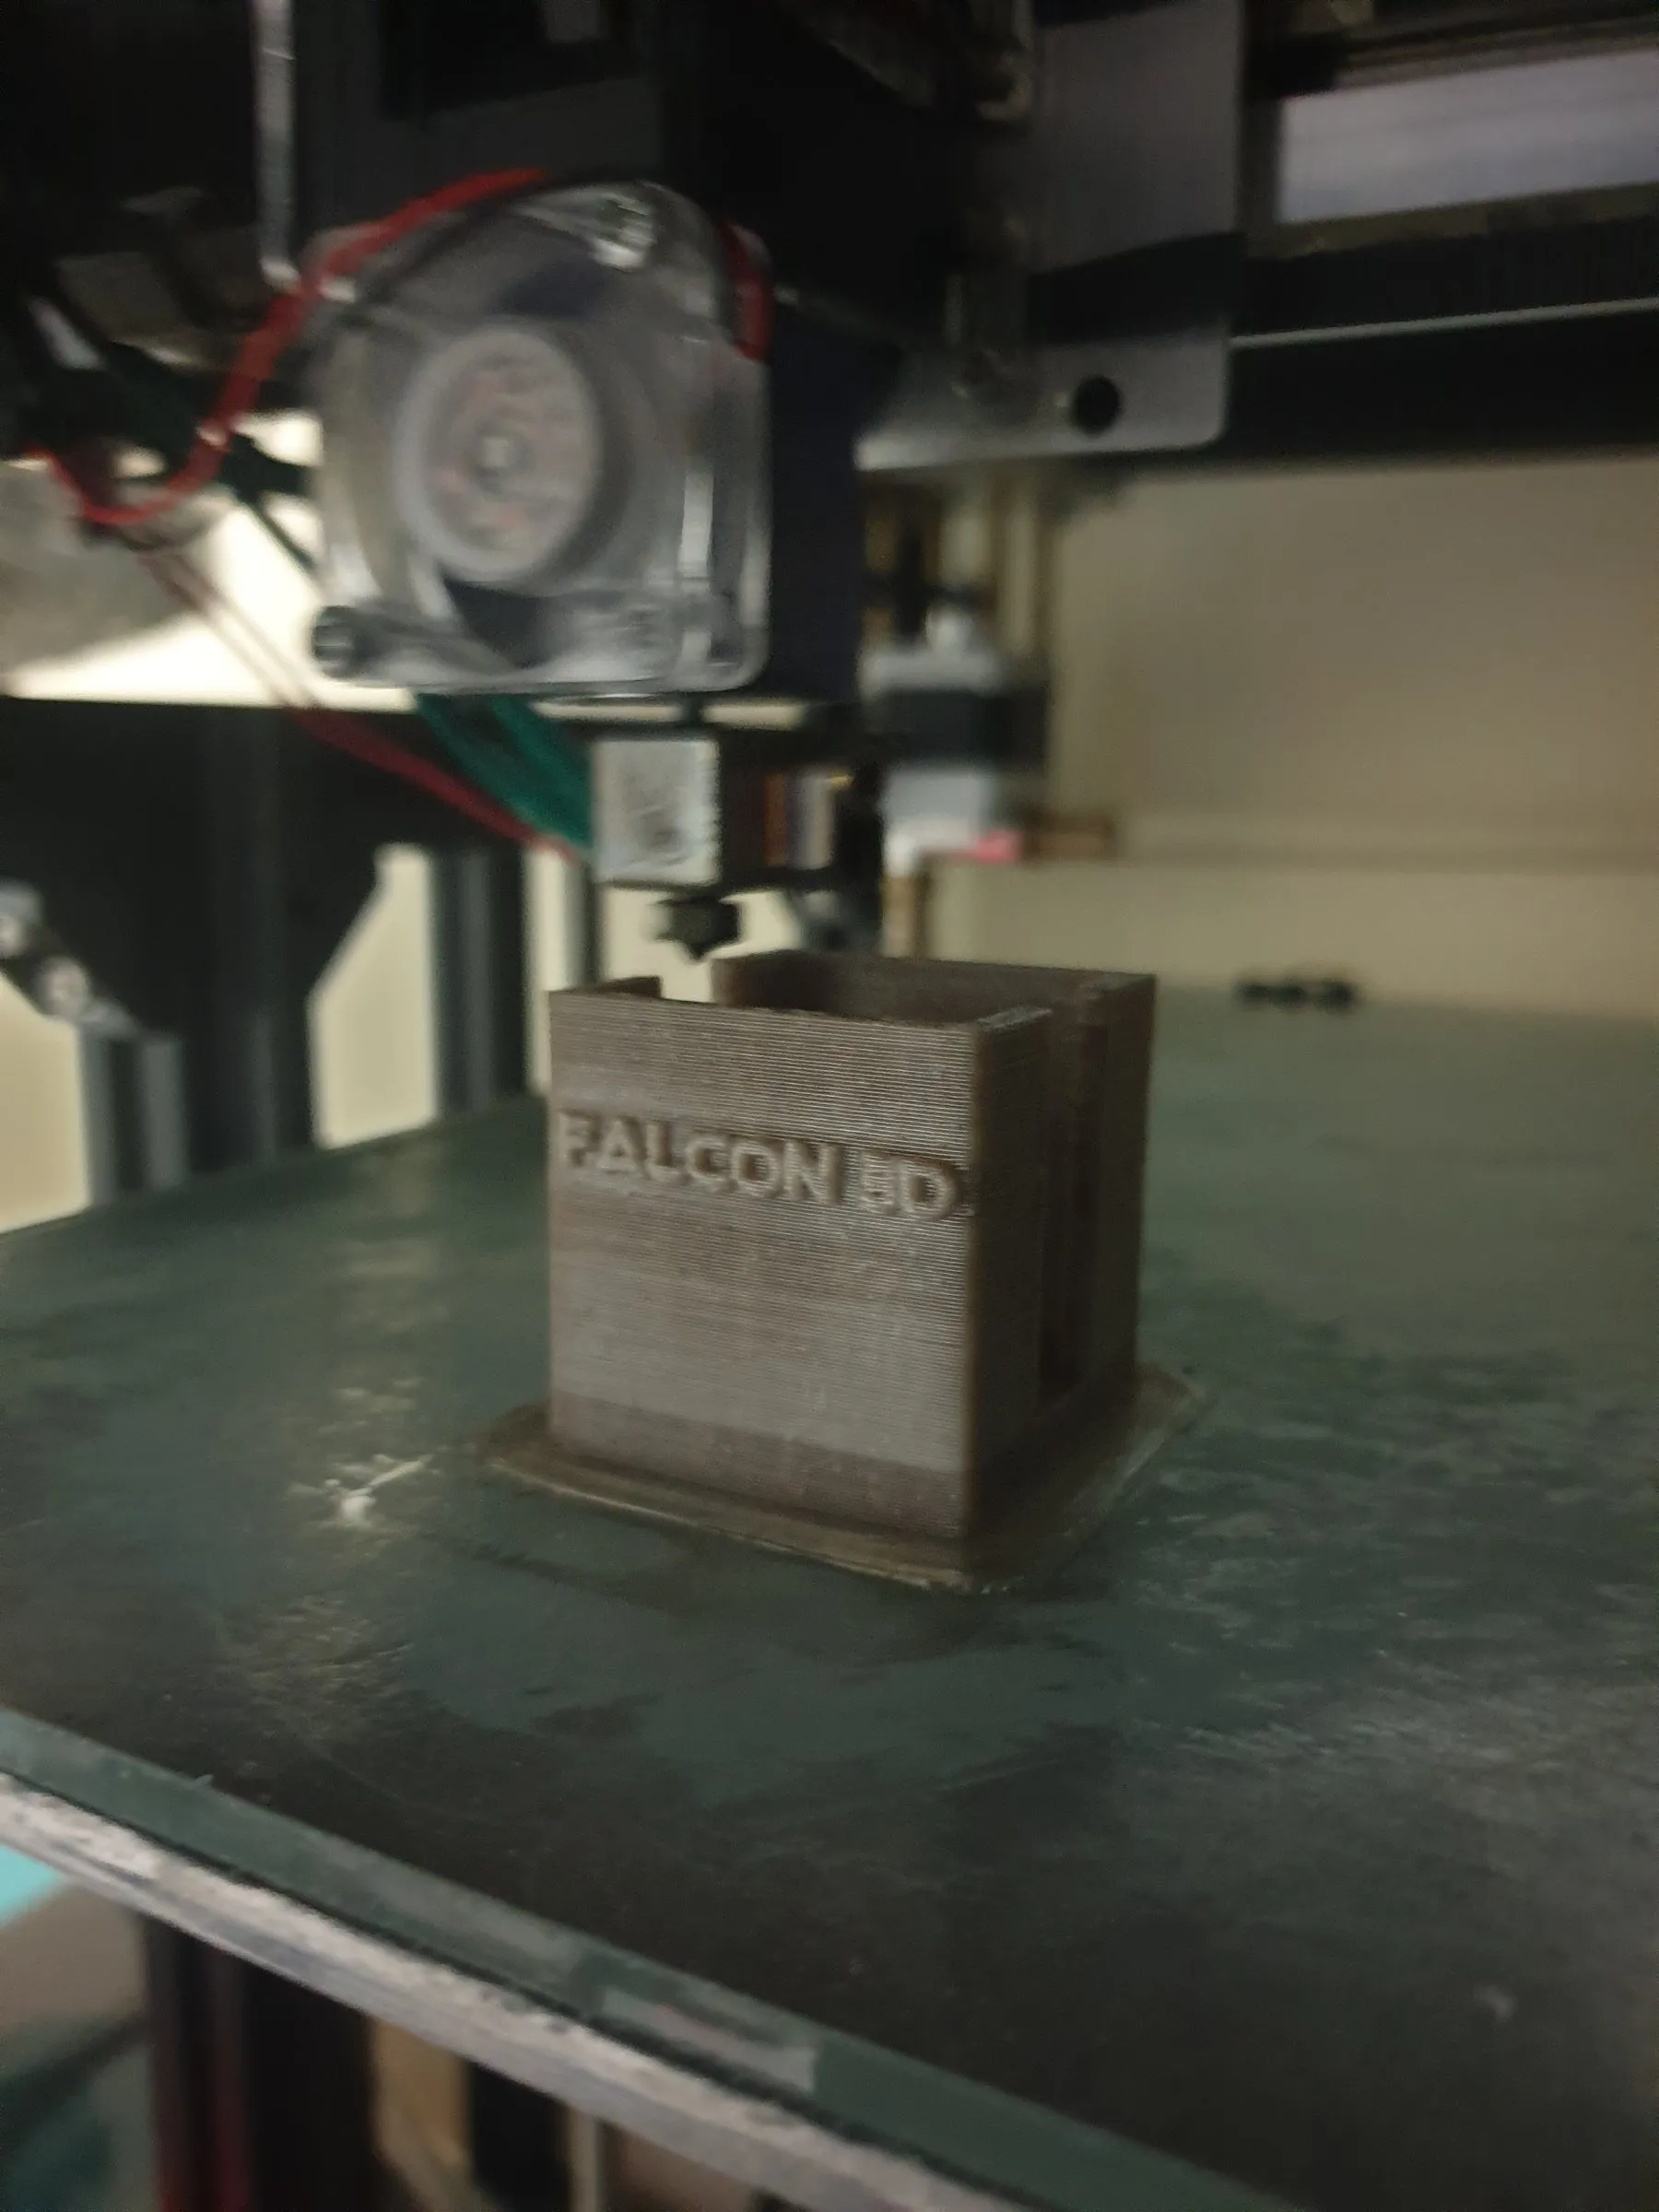
A hardware startup building high-precision 3D printers, motion systems and automation for industrial customers.

  • PEEK 3D printer licensed to dental professionals
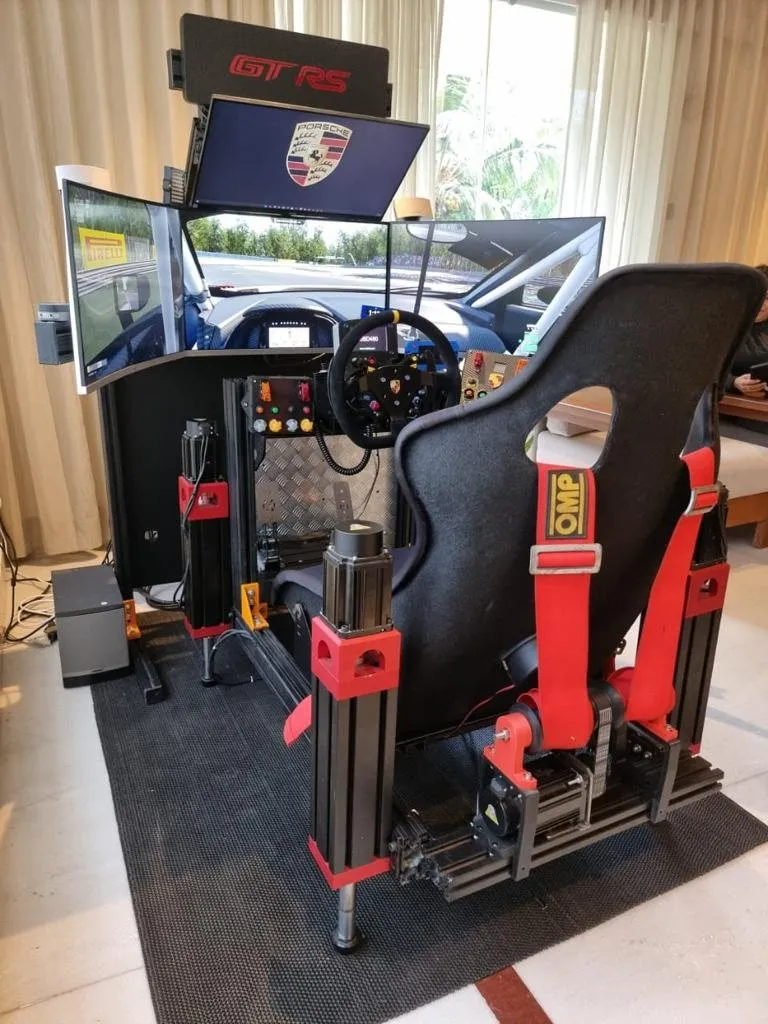
  • Racing-simulator actuator unit sold to DRDO
  • Automated FDM print farm for continuous production
  • A 3D printer sold in 2018 is still running in Chennai, India, with regular maintenance

Experience

Where I've worked

Two startups of my own, three medical-device companies, and research at the University at Buffalo.

Pebble Robotics

Buffalo, NY

Current

Co-founder

2026 – present

Building an autonomous home robot. Built the first complete robot alone in four months, then formed a five-person team. I lead hardware and the five-unit pilot build.

University at Buffalo

Buffalo, NY

M.S. research: high-density EMG wearable

Sep 2025 – present

Analog front end, flex PCB and electrode-array enclosure for a multiplexed EMG wearable. The first prototype has four electrodes; I am expanding it to 8 channels. Advisor: Prof. Filip Stefanovic.

Robotics Assistant, DREAM Lab

Sep 2025 – present

Run weekly robotic-arm workshops, from block coding on desktop arms to programming industrial arms.

Venture Coach, UB CoLab (Blackstone LaunchPad)

Sep 2025 – May 2026

Mentored 10+ student founders turning research ideas into manufacturable hardware products.

TEMPLE

Hardware Engineer / Head of Production

Sep 2024 – Jun 2025

Took a sub-4 mm cerebral blood-flow wearable from R&D to production: injection molding, over-molding and ultrasonic welding with suppliers in China and Japan. Built and shipped the first 200 units in-house in two months.

PIIKO

Senior Engineer, R&D

Nov 2021 – Aug 2024

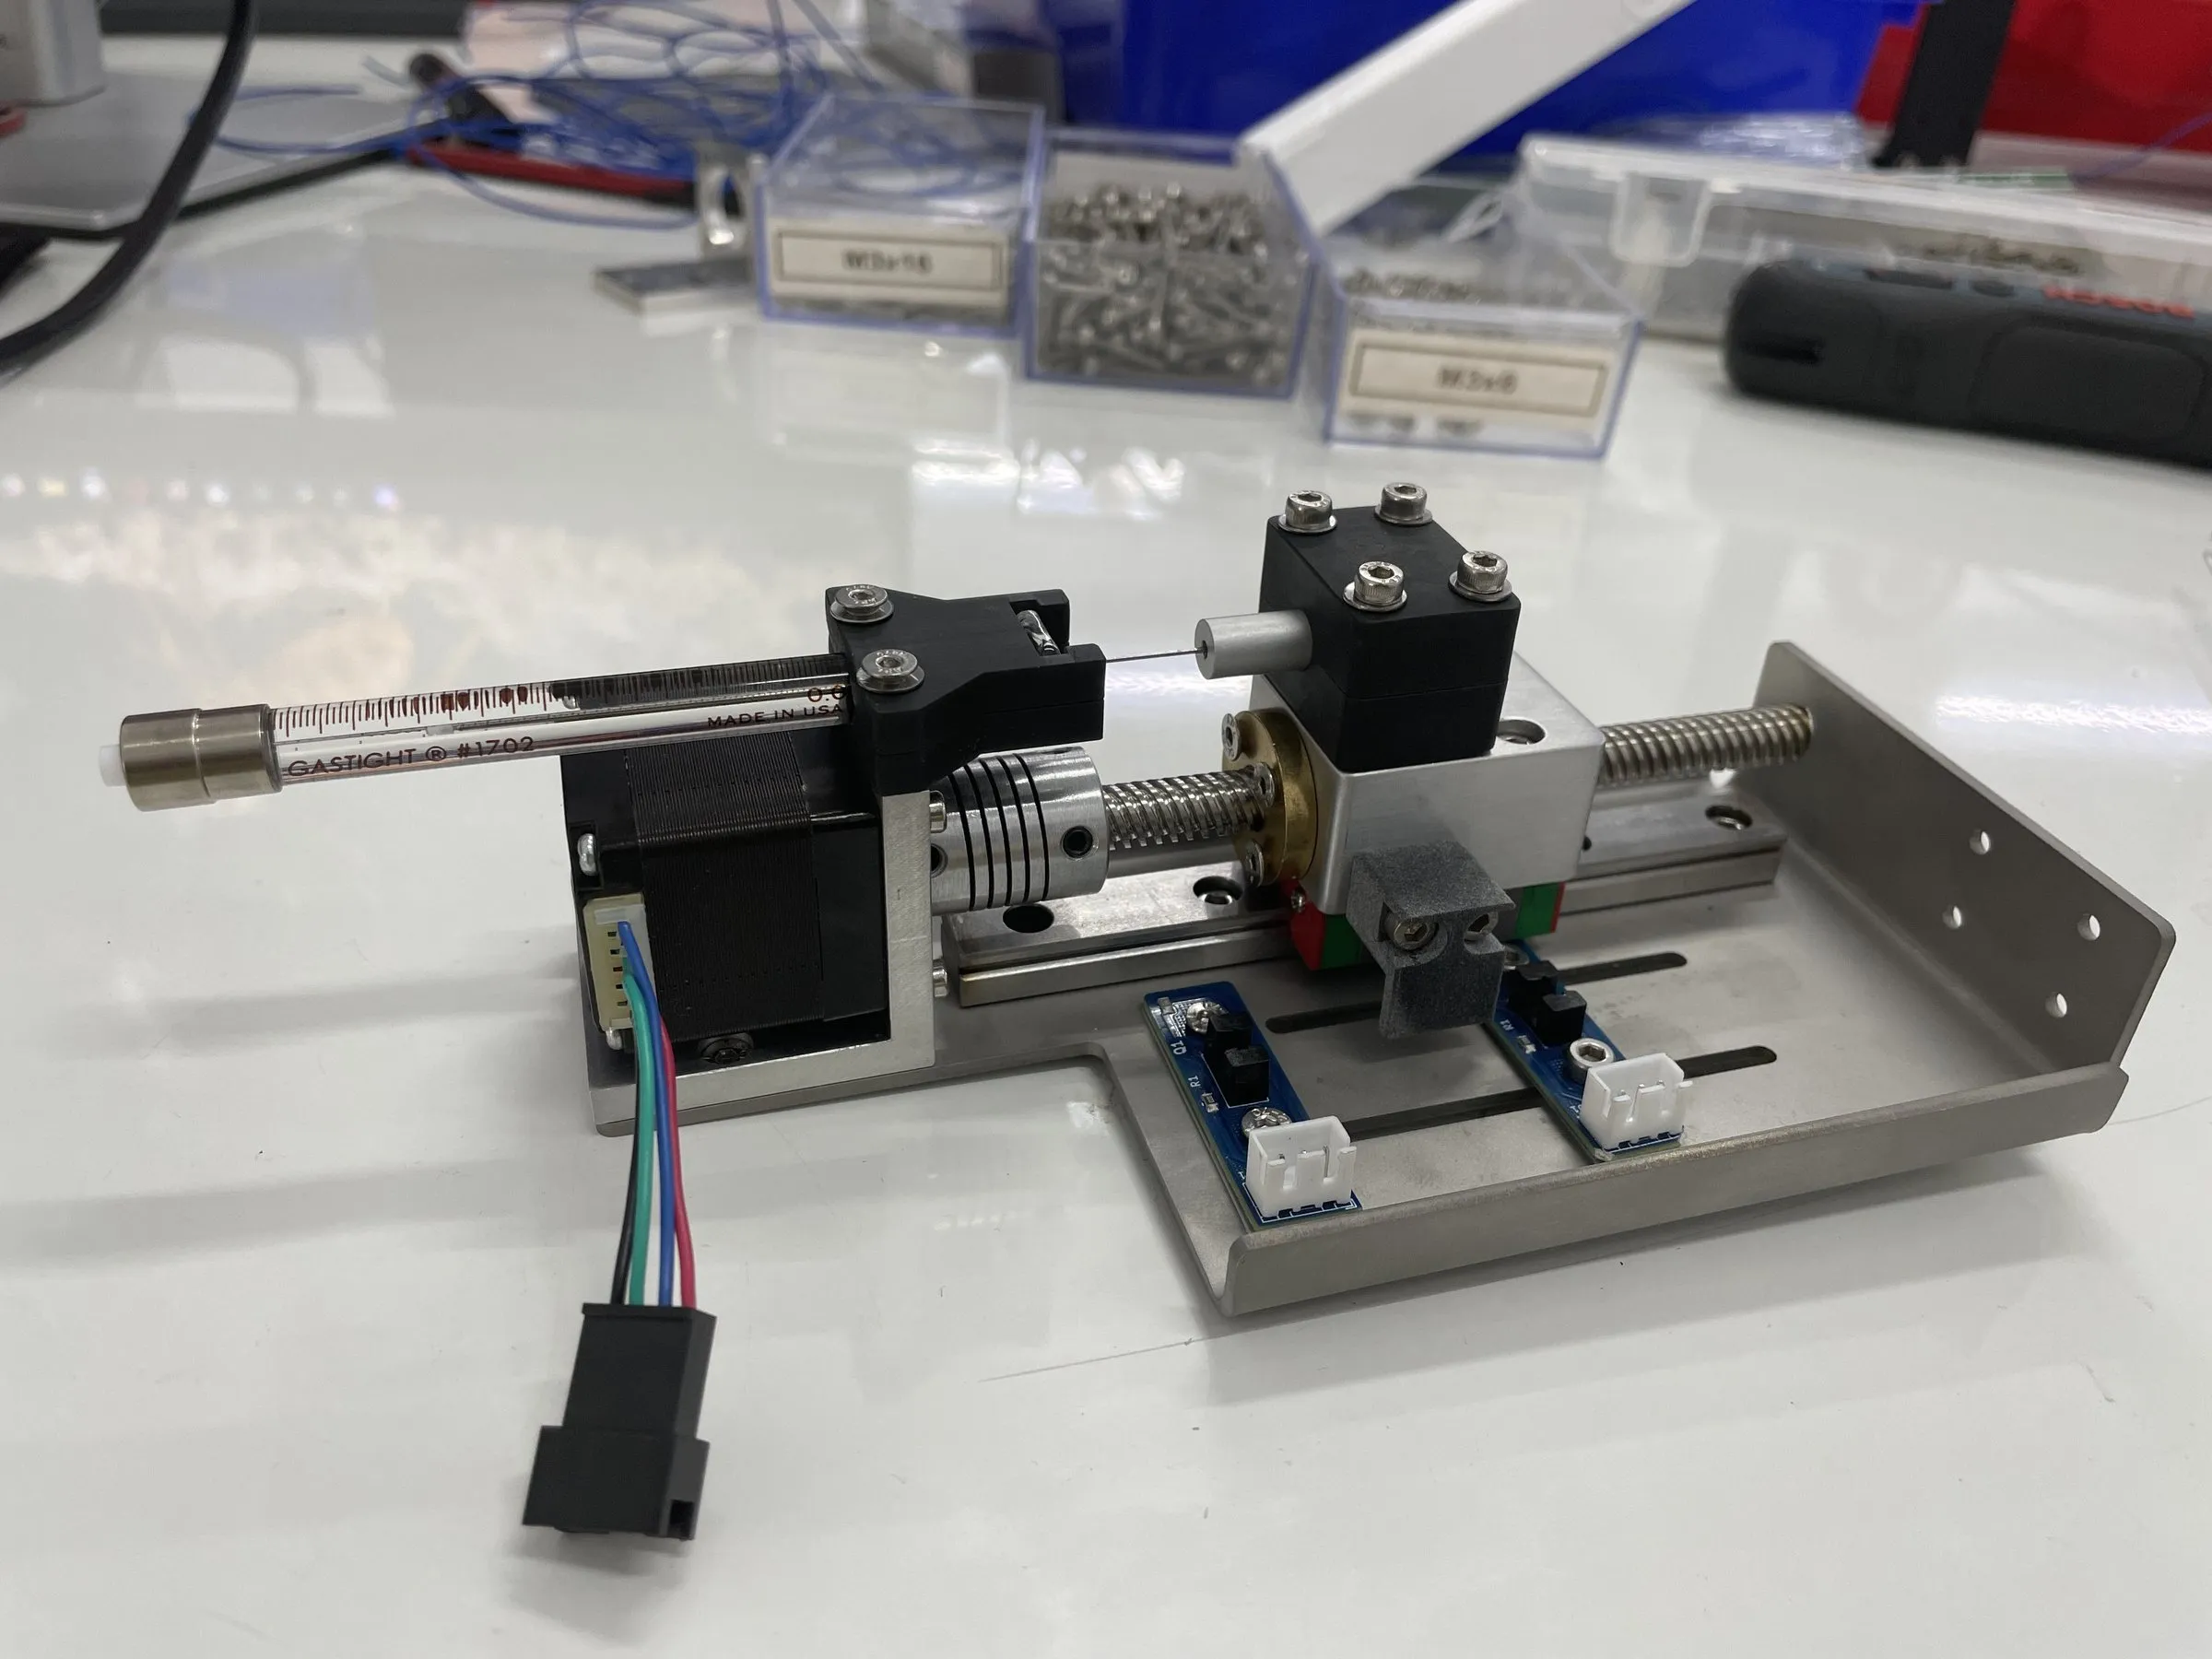
Led design of a CBC blood analyzer through production: 50+ units shipped, 10× lower cost per test. Built an in-house syringe pump (0.1 µL) and a reagent filling line (4,500 kits a day).

Motherson Medical

Embedded Systems Engineer

Dec 2020 – Nov 2021

Developed automated microscopy systems for cellular imaging, and designed slides and fixtures for repeatable cell counts.

Falcon 3D

India

Founder & CEO

Jul 2017 – Nov 2020

Founded and ran a hardware startup building high-precision 3D printers and motion systems, from a PEEK printer for dental work to a print farm.

Technical skills

Mechanical, electrical and biomedical

An electrical engineering degree, mechanical design in industry and a biomedical master's: I design the enclosure and the PCB inside it.

Software

  • SolidWorks (CSWA)
  • KeyShot
  • KiCad
  • Altium
  • MATLAB
  • Python

Mechanical design

  • GD&T and tolerance analysis
  • Precision mechanisms
  • Motion systems and gantries
  • Thermal and structural design

Manufacturing

  • Injection and over-molding
  • Ultrasonic welding
  • CNC machining
  • DFM, DFA and DFX
  • Production line setup
  • Suppliers in China and Japan

Electronics

  • PCB and flex PCB design
  • Analog circuits
  • Electronics–mechanical co-design
  • ESP32, Raspberry Pi, Arduino

Medical devices

  • FDA documentation (Class I and II)
  • ISO 13485
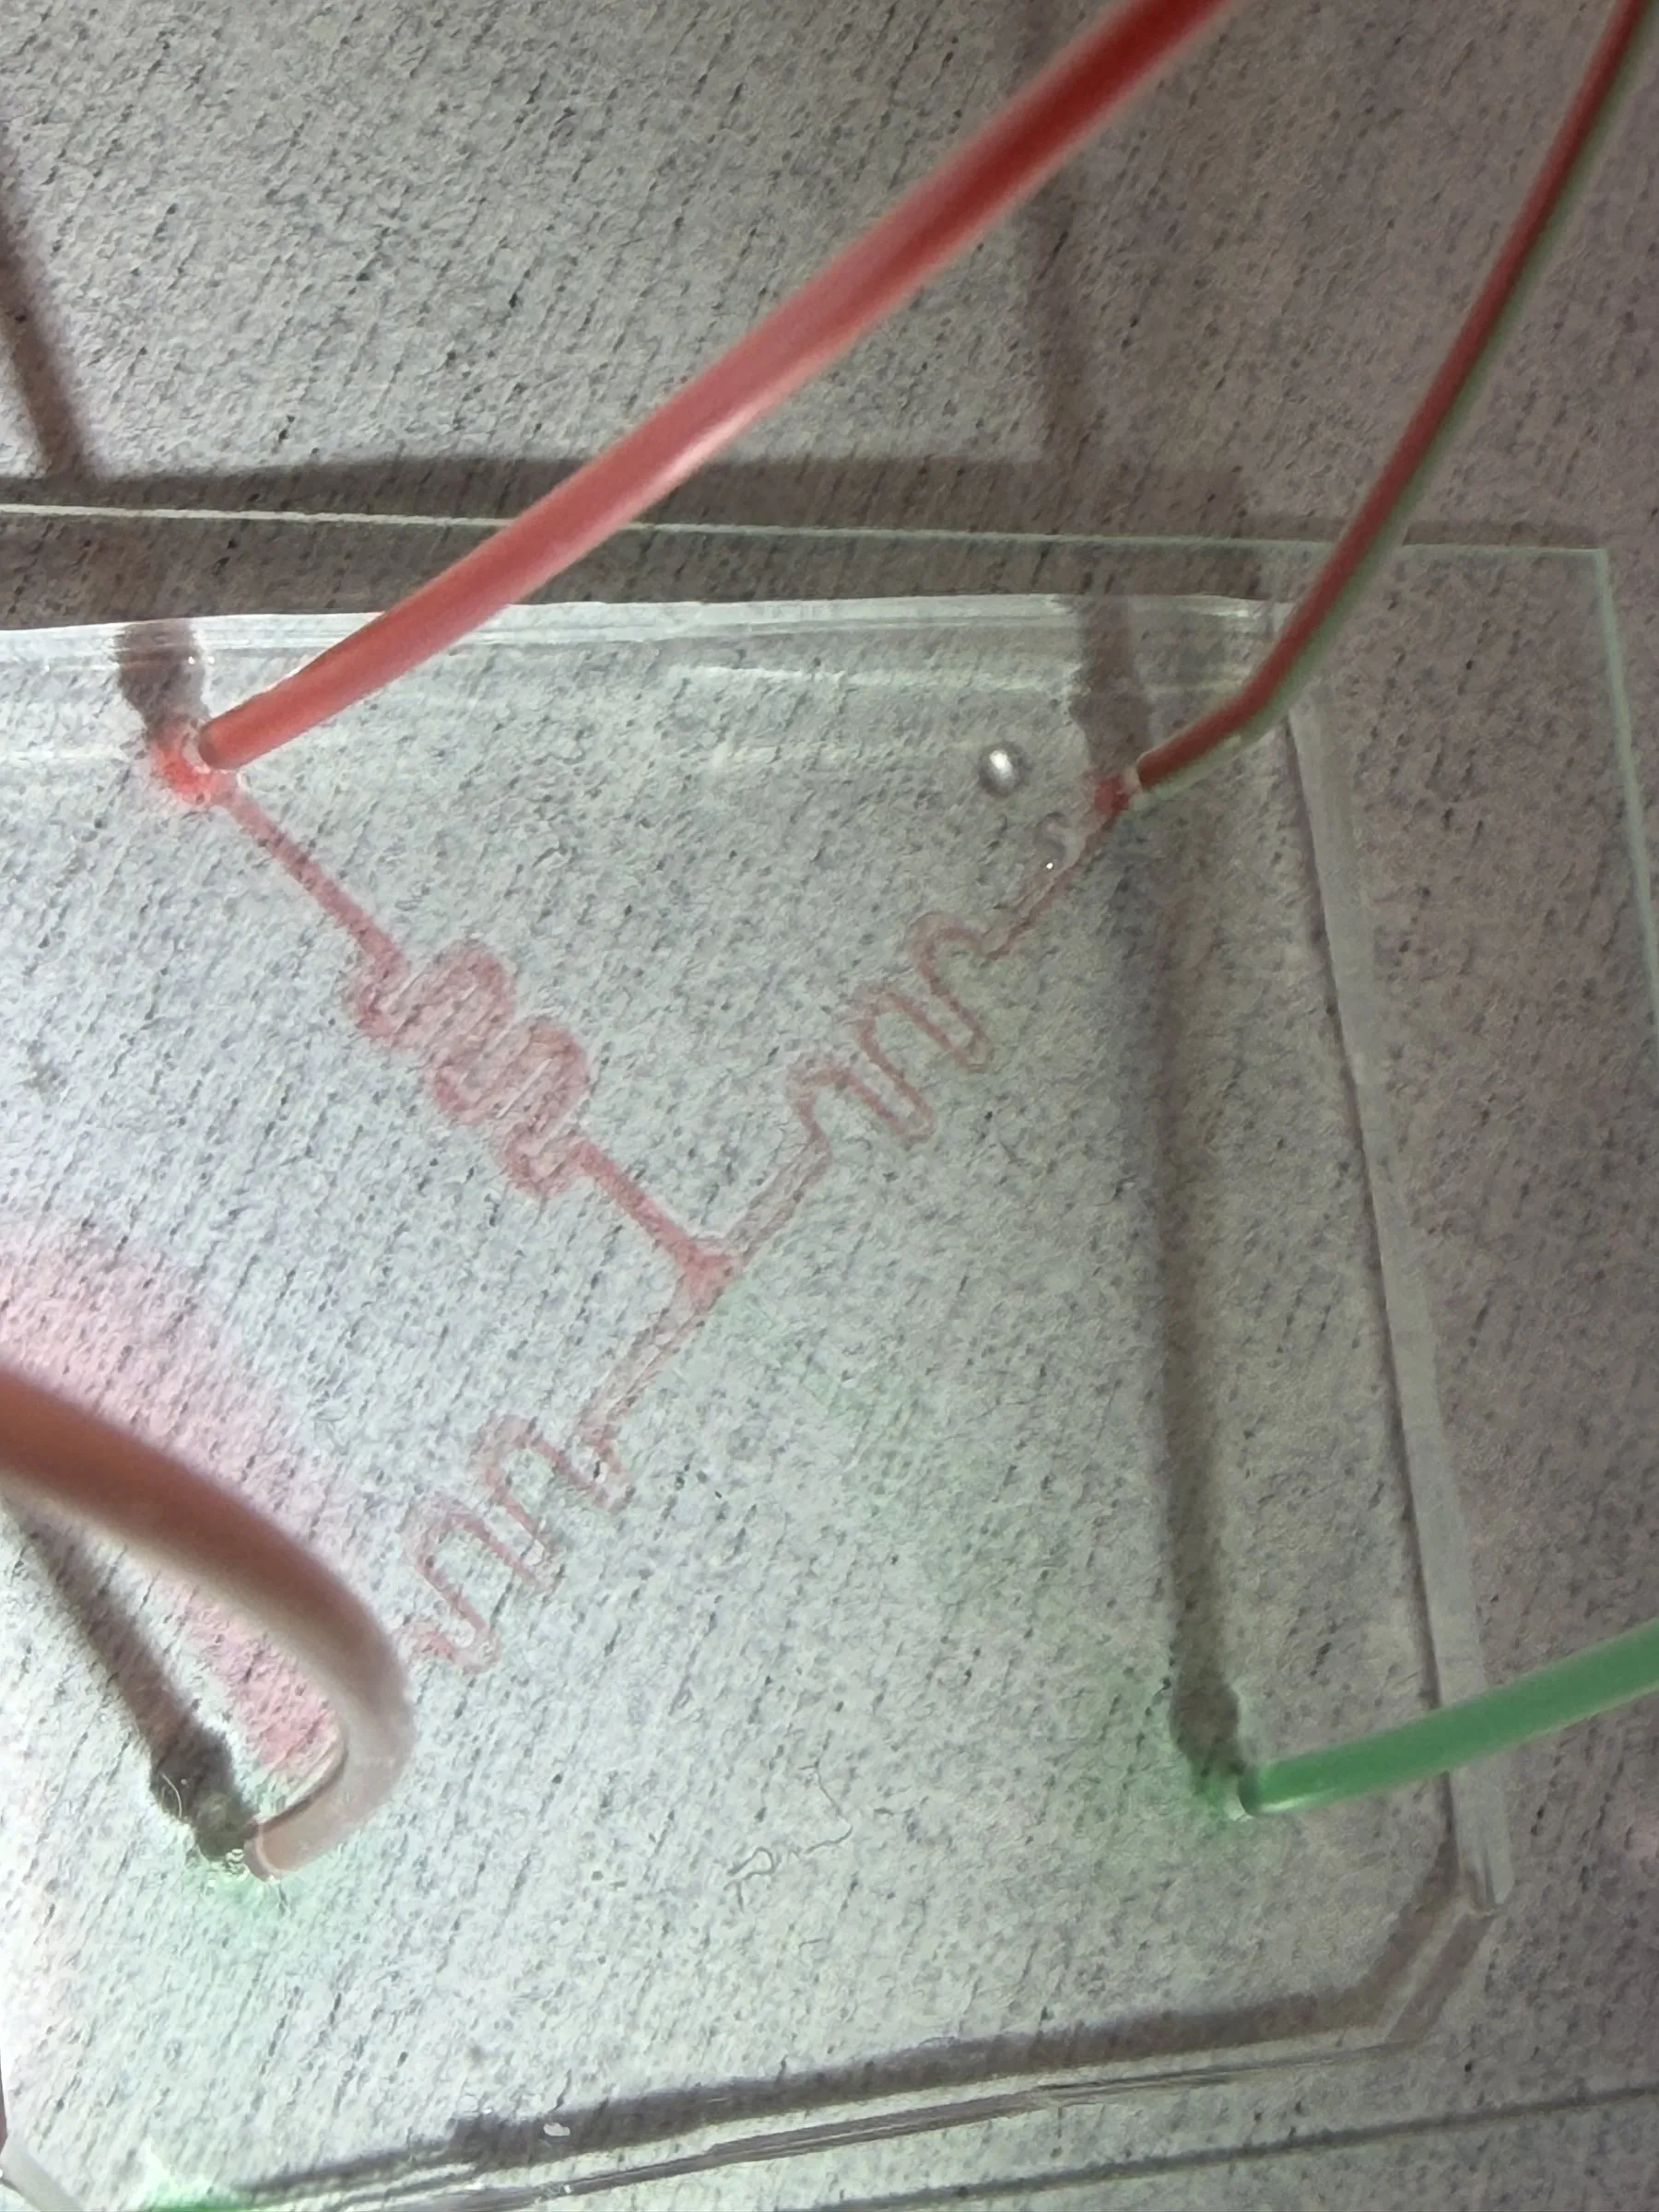
  • Microfluidics and PDMS
  • Cleanroom photolithography

Robotics and prototyping

  • Autonomous robots
  • Motor control (PID)
  • LiDAR, radar and IMU sensors
  • 3D printing (SLA, FDM, MJF)
  • 3D printer design

Aug 2025 – Dec 2026

University at Buffalo

M.S. Biomedical Engineering

2016 – 2020

Anna University

B.E. Electrical & Electronics Engineering

Certifications

  • SolidWorks CSWA

Teaching & community

Helping others build

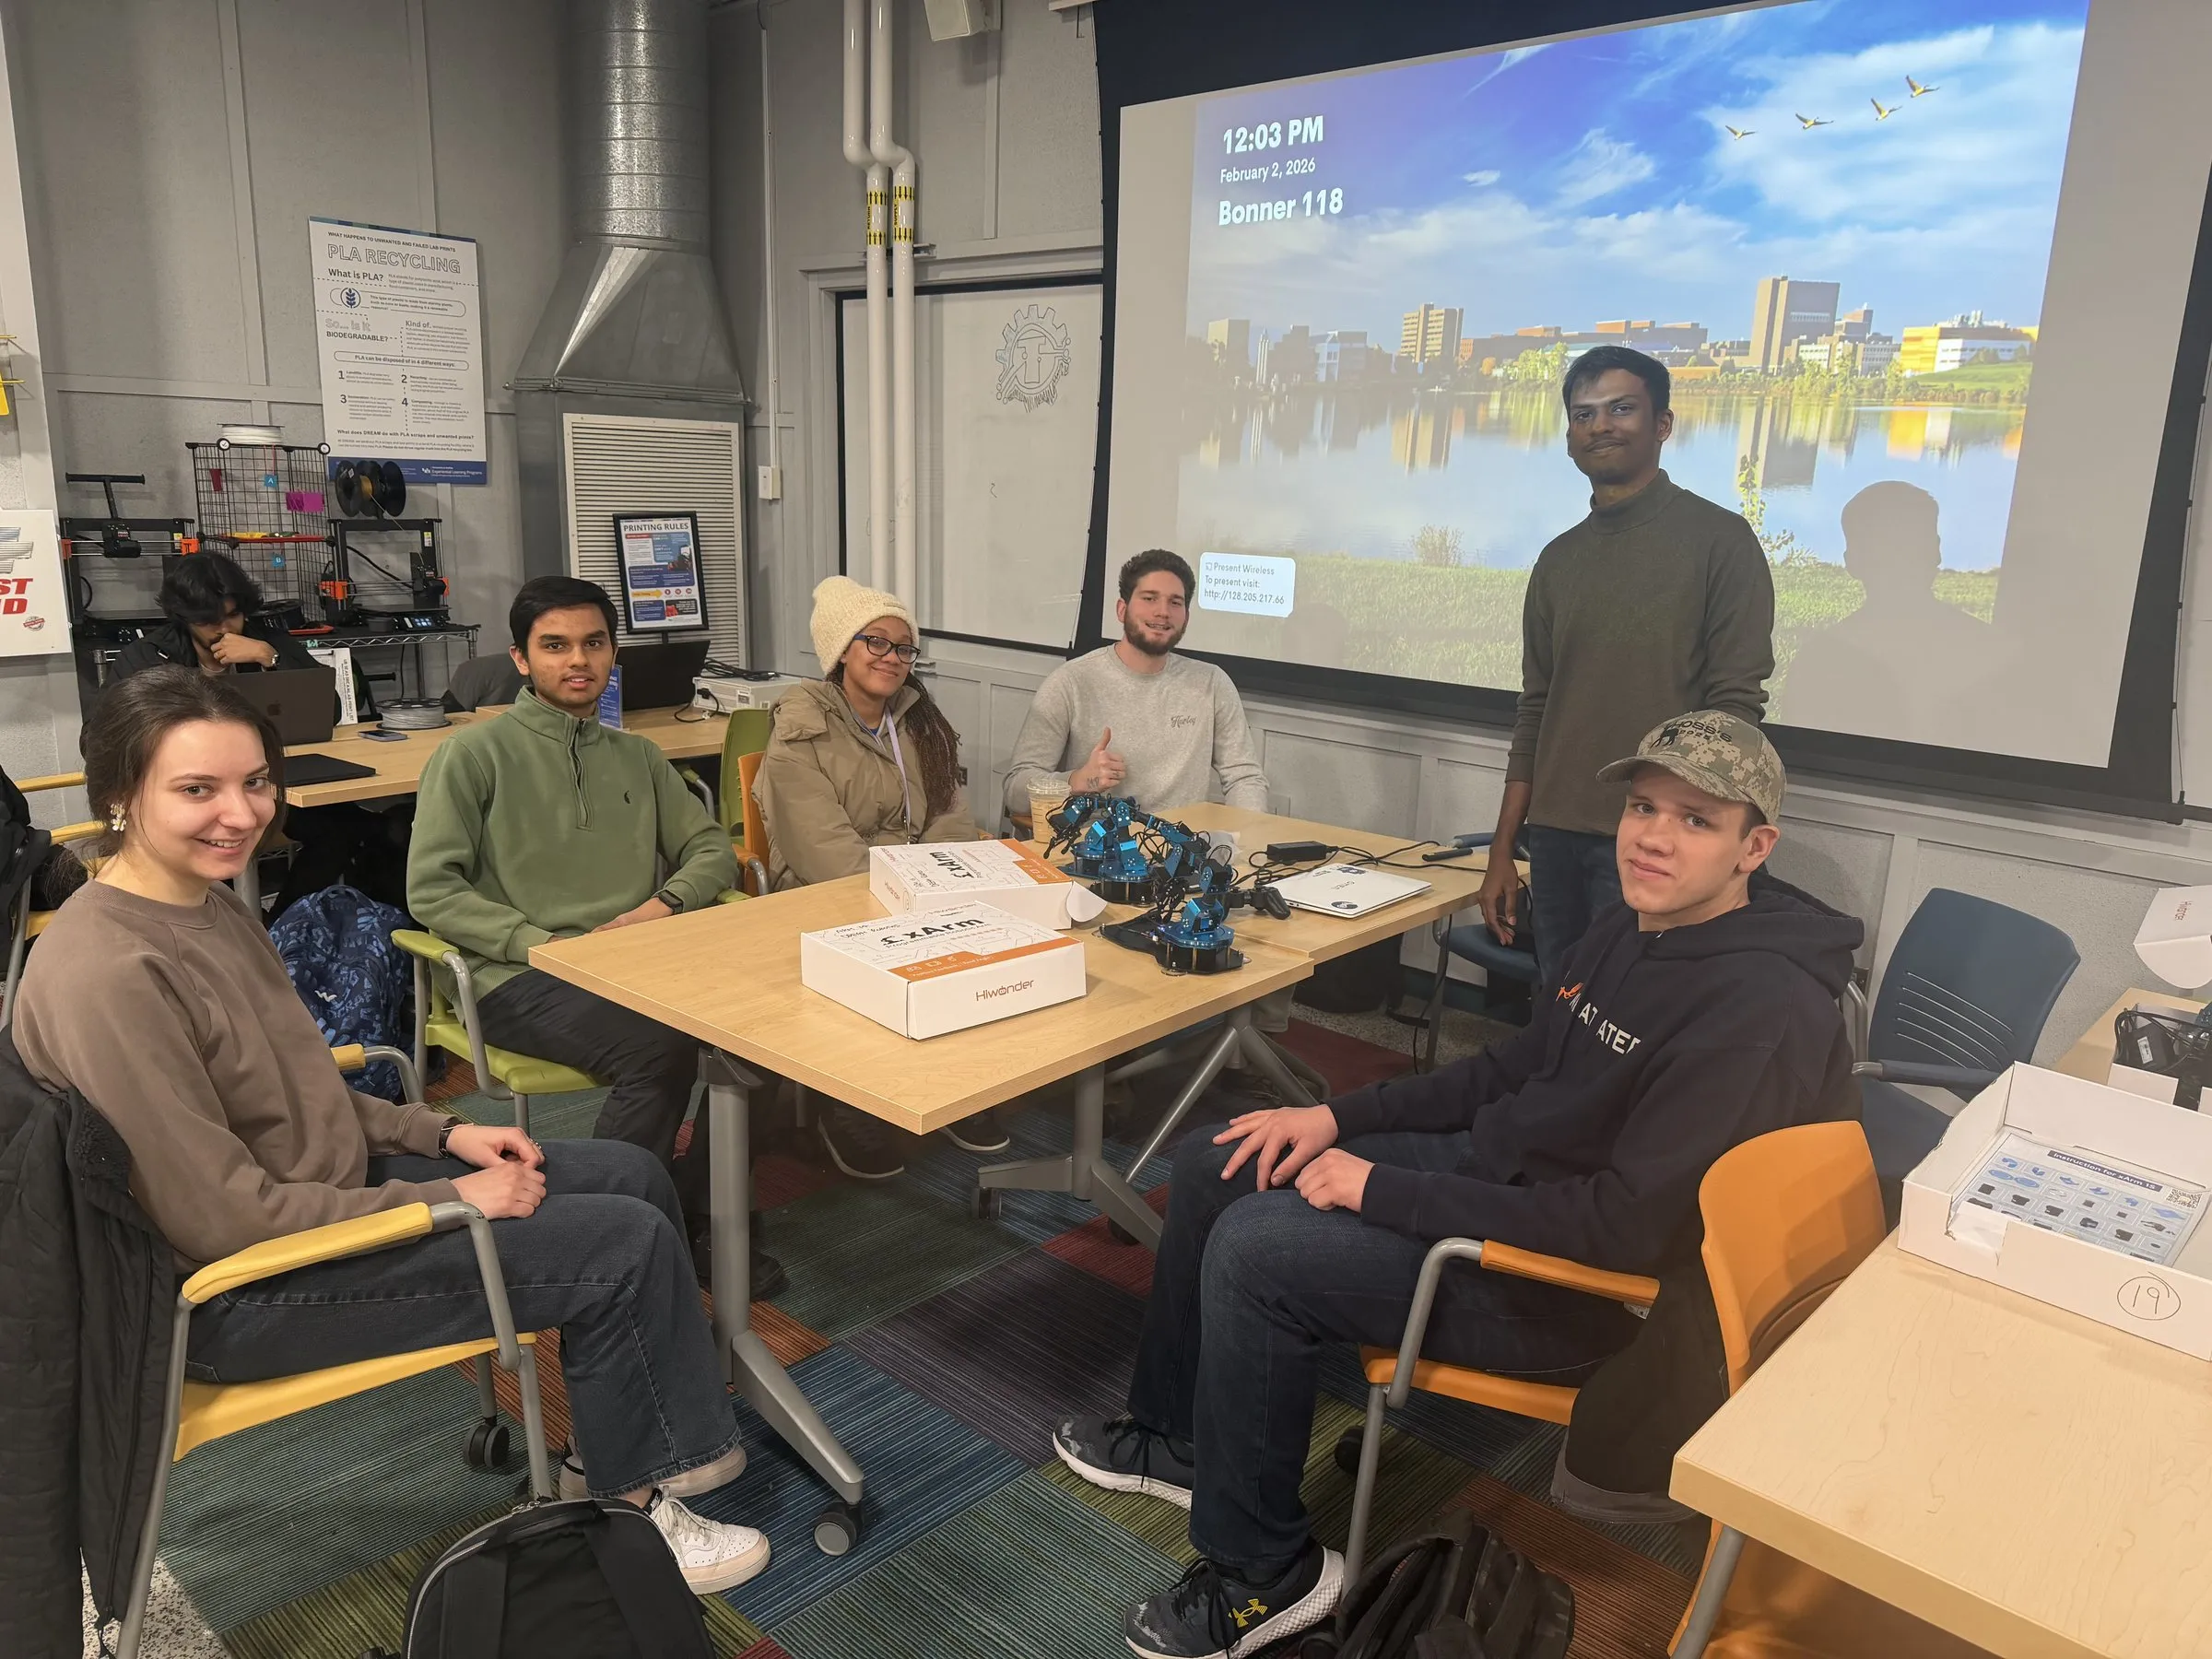
Kumar presenting to students at a robotic-arm workshop in the DREAM Lab
Robotic-arm workshop, UB DREAM Lab
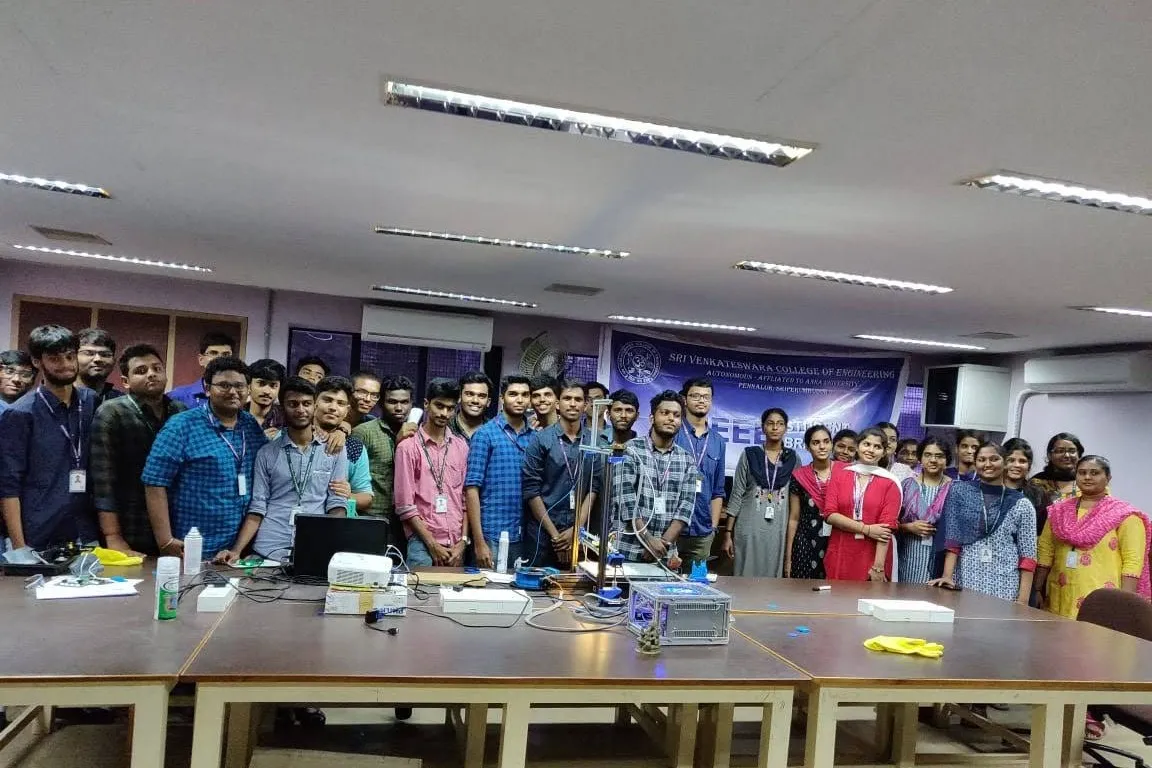
Workshop participants gathered for a group photo in front of an IEEE Student Branch banner, with 3D printers on the tables
3D printing workshop, IEEE Student Branch, 2018

UB DREAM Lab · 2025 – present

Robotic-arm workshop series

Weekly hands-on sessions that move from block coding on desktop arms to programming an industrial arm, ending in a competition.

UB CoLab (Blackstone LaunchPad) · 2025 – 2026

Venture coaching

Mentored 10+ student founders on turning research concepts into manufacturable, scalable hardware.

IEEE Student Branch · 2018

3D printing workshop

Taught design, fabrication and additive manufacturing fundamentals through hands-on builds.